Multi-UAV system for autonomous inspection
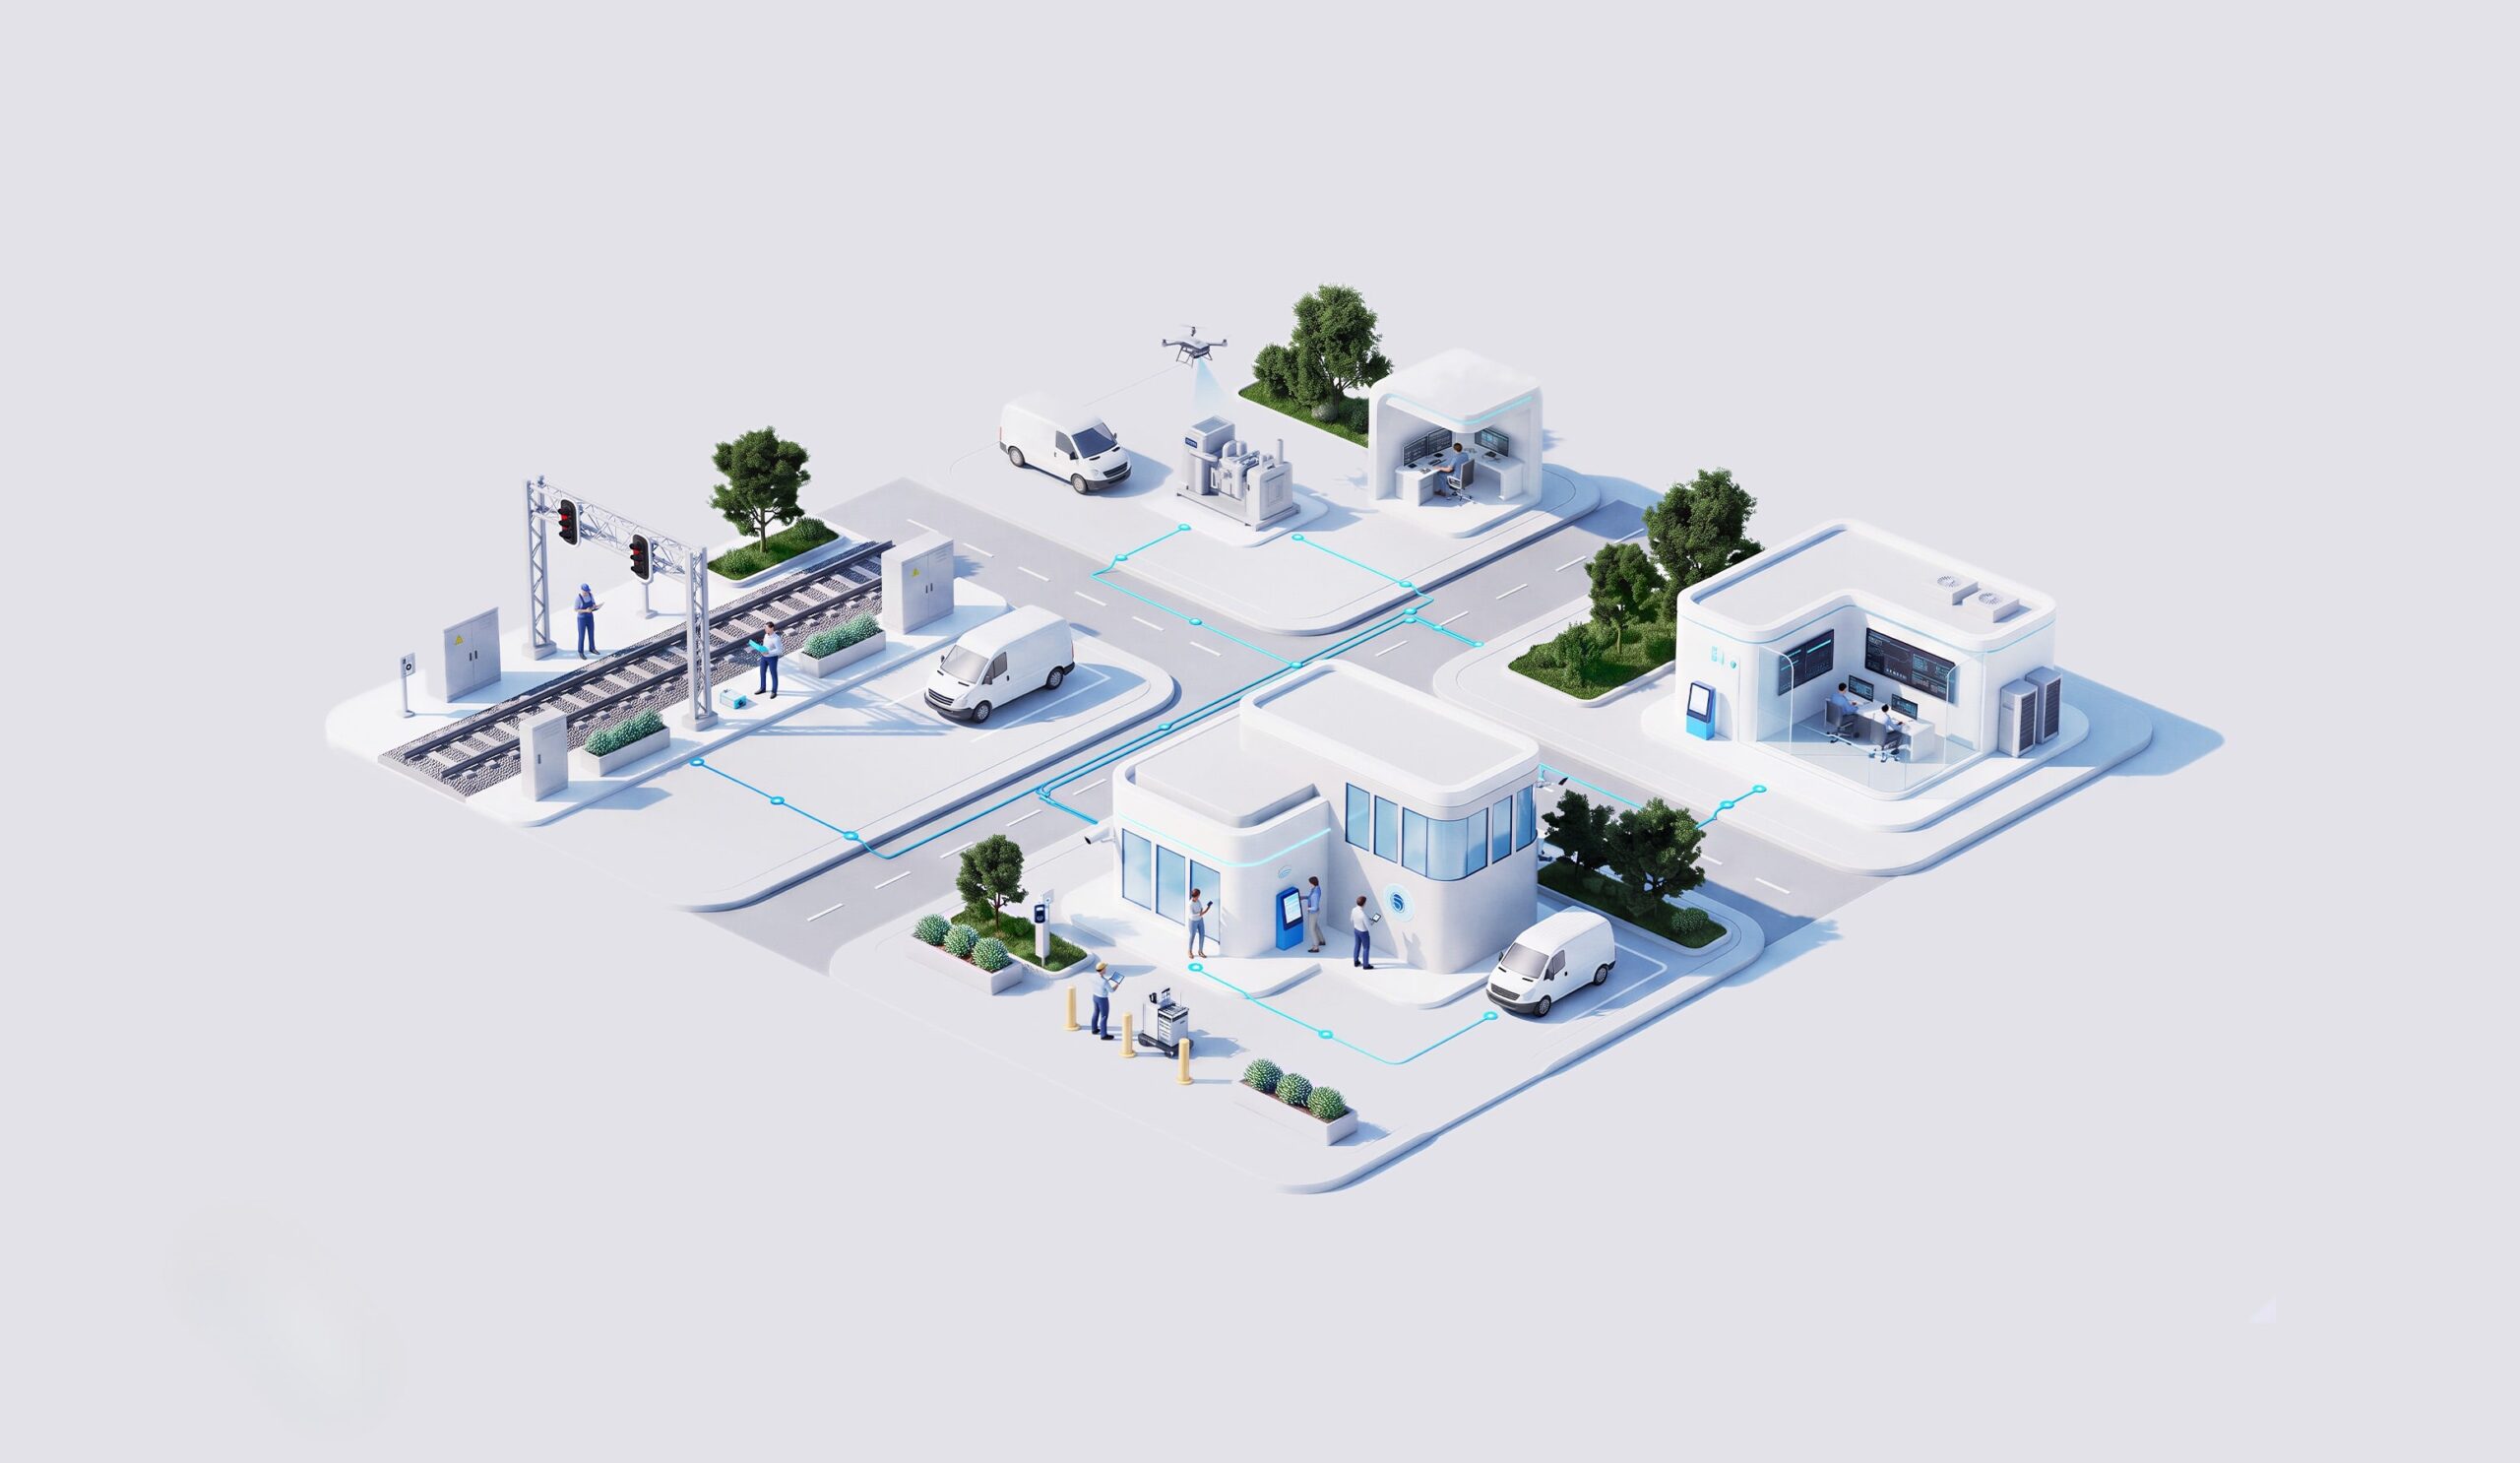
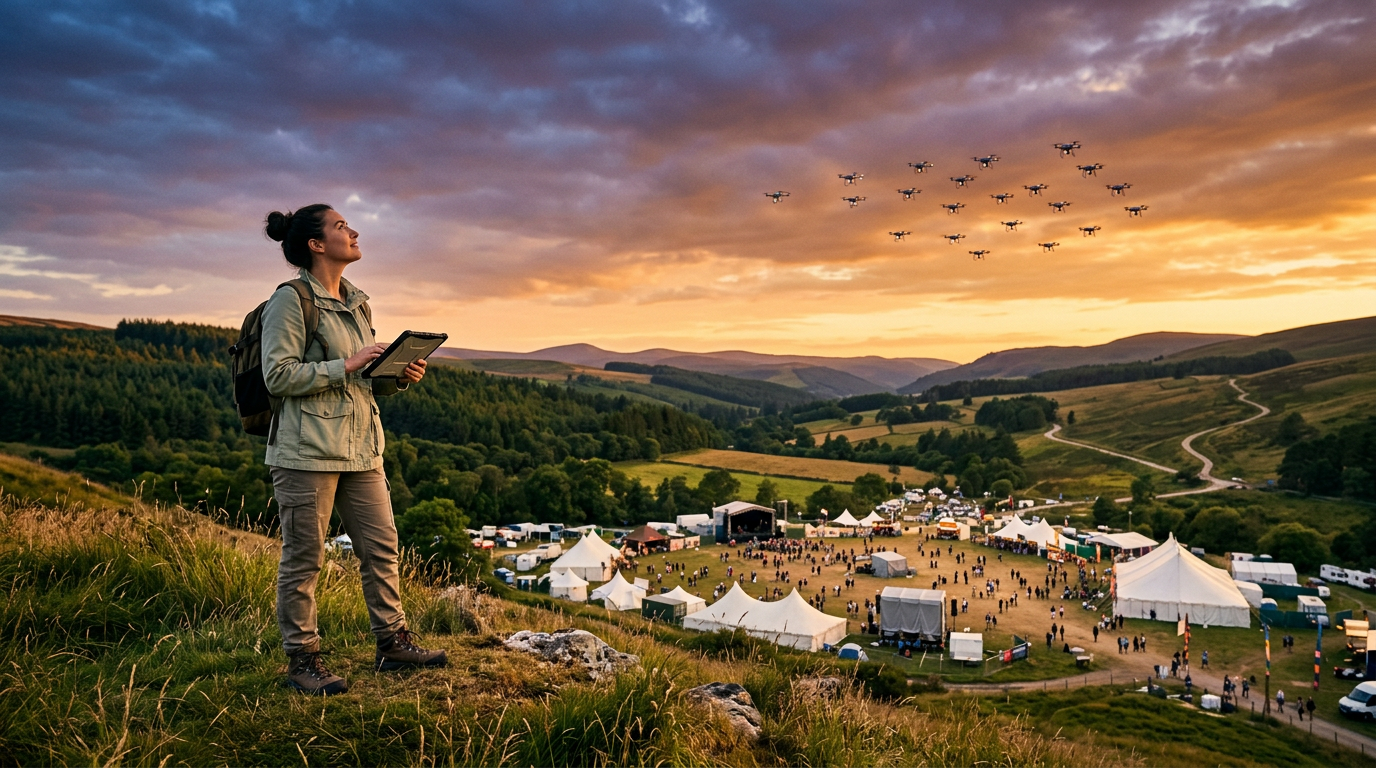
Critical infrastructure and private areas need constant watching, and fixed surveillance leaves gaps across large sites. NTT DATA applied artificial intelligence to build a multi-UAV system for autonomous patrolling. Reinforcement learning optimizes every flight path, and computer vision designed for bad weather keeps inspection results reliable.
Flight planning: Reinforcement learning
Drones optimize their paths against several objectives at once.
Patrol coverage: Complete
Routes aim to cover the entire assigned area.
Fleet links: Robust
Optimization keeps drones in contact during coordinated missions.
Inspection conditions: Rain, fog and changing light
Computer vision analysis holds up in poor weather.
Cooperative Networked UAVs
Faster, more accurate surveillance for critical infrastructure
目的
Improve the responsiveness and accuracy of surveillance, protect infrastructure integrity and reduce security risks in private areas.
機会
Autonomous drones report on the condition and security of essential assets in real time, and the same system adapts to patrols in other domains.
Large sites, fixed cameras

A fixed camera watches one point. Critical infrastructure spreads across wide areas where weather, light and threats keep changing, and patrols on foot or by car cover only part of the ground.
主な課題
1: Coverage gaps. Fixed surveillance leaves parts of large sites unwatched.
2: Competing objectives. Each mission must cover the whole area and keep the drones connected to each other.
3: Weather and lighting. Rain, fog and shifting light degrade visual inspection.
4: Response time. Security teams need detection and threat assessment as events unfold.
解決策
A cooperative fleet guided by reinforcement learning

NTT DATA designed a fleet of drones which optimize their flight paths with reinforcement learning (RL), combined with weather-resilient computer vision. The system runs on Python, ROS and Docker.

チェックアイコン
Multi-UAV control framework

A learning engine and a control interface manage the drones as one system, each running a programmable protocol stack.

チェックアイコン
RL-based flight optimization

The RL model adjusts each route to make the mission more effective, starting with complete area coverage during patrols.

チェックアイコン
Communication-aware routing

The same optimization protects the links between drones so they operate in coordination, with the fleet ready for next-generation networks such as IOWN.

チェックアイコン
Weather-resilient computer vision

Inspection algorithms analyze visual data accurately in rain, fog or changing light.

影響
Patrols with live detection and threat assessment

Security teams see threats as the drones detect them, with an assessment attached. RL-driven flight optimization and weather-resistant computer vision give operators a robust, adaptable option for autonomous inspection and surveillance. Every image and inspection record stays under the infrastructure operator’s control.
ドラッグ