


- All Foundries

- Commodity Management & Trading

- Customer & Marketing Strategy

- Digital Engineering

- Station Studio

- Supply Chain & Industry 5.0
- Sustainability

- Physical AI

- Next-Gen Infrastructure

Vision-Based Robotic Picking
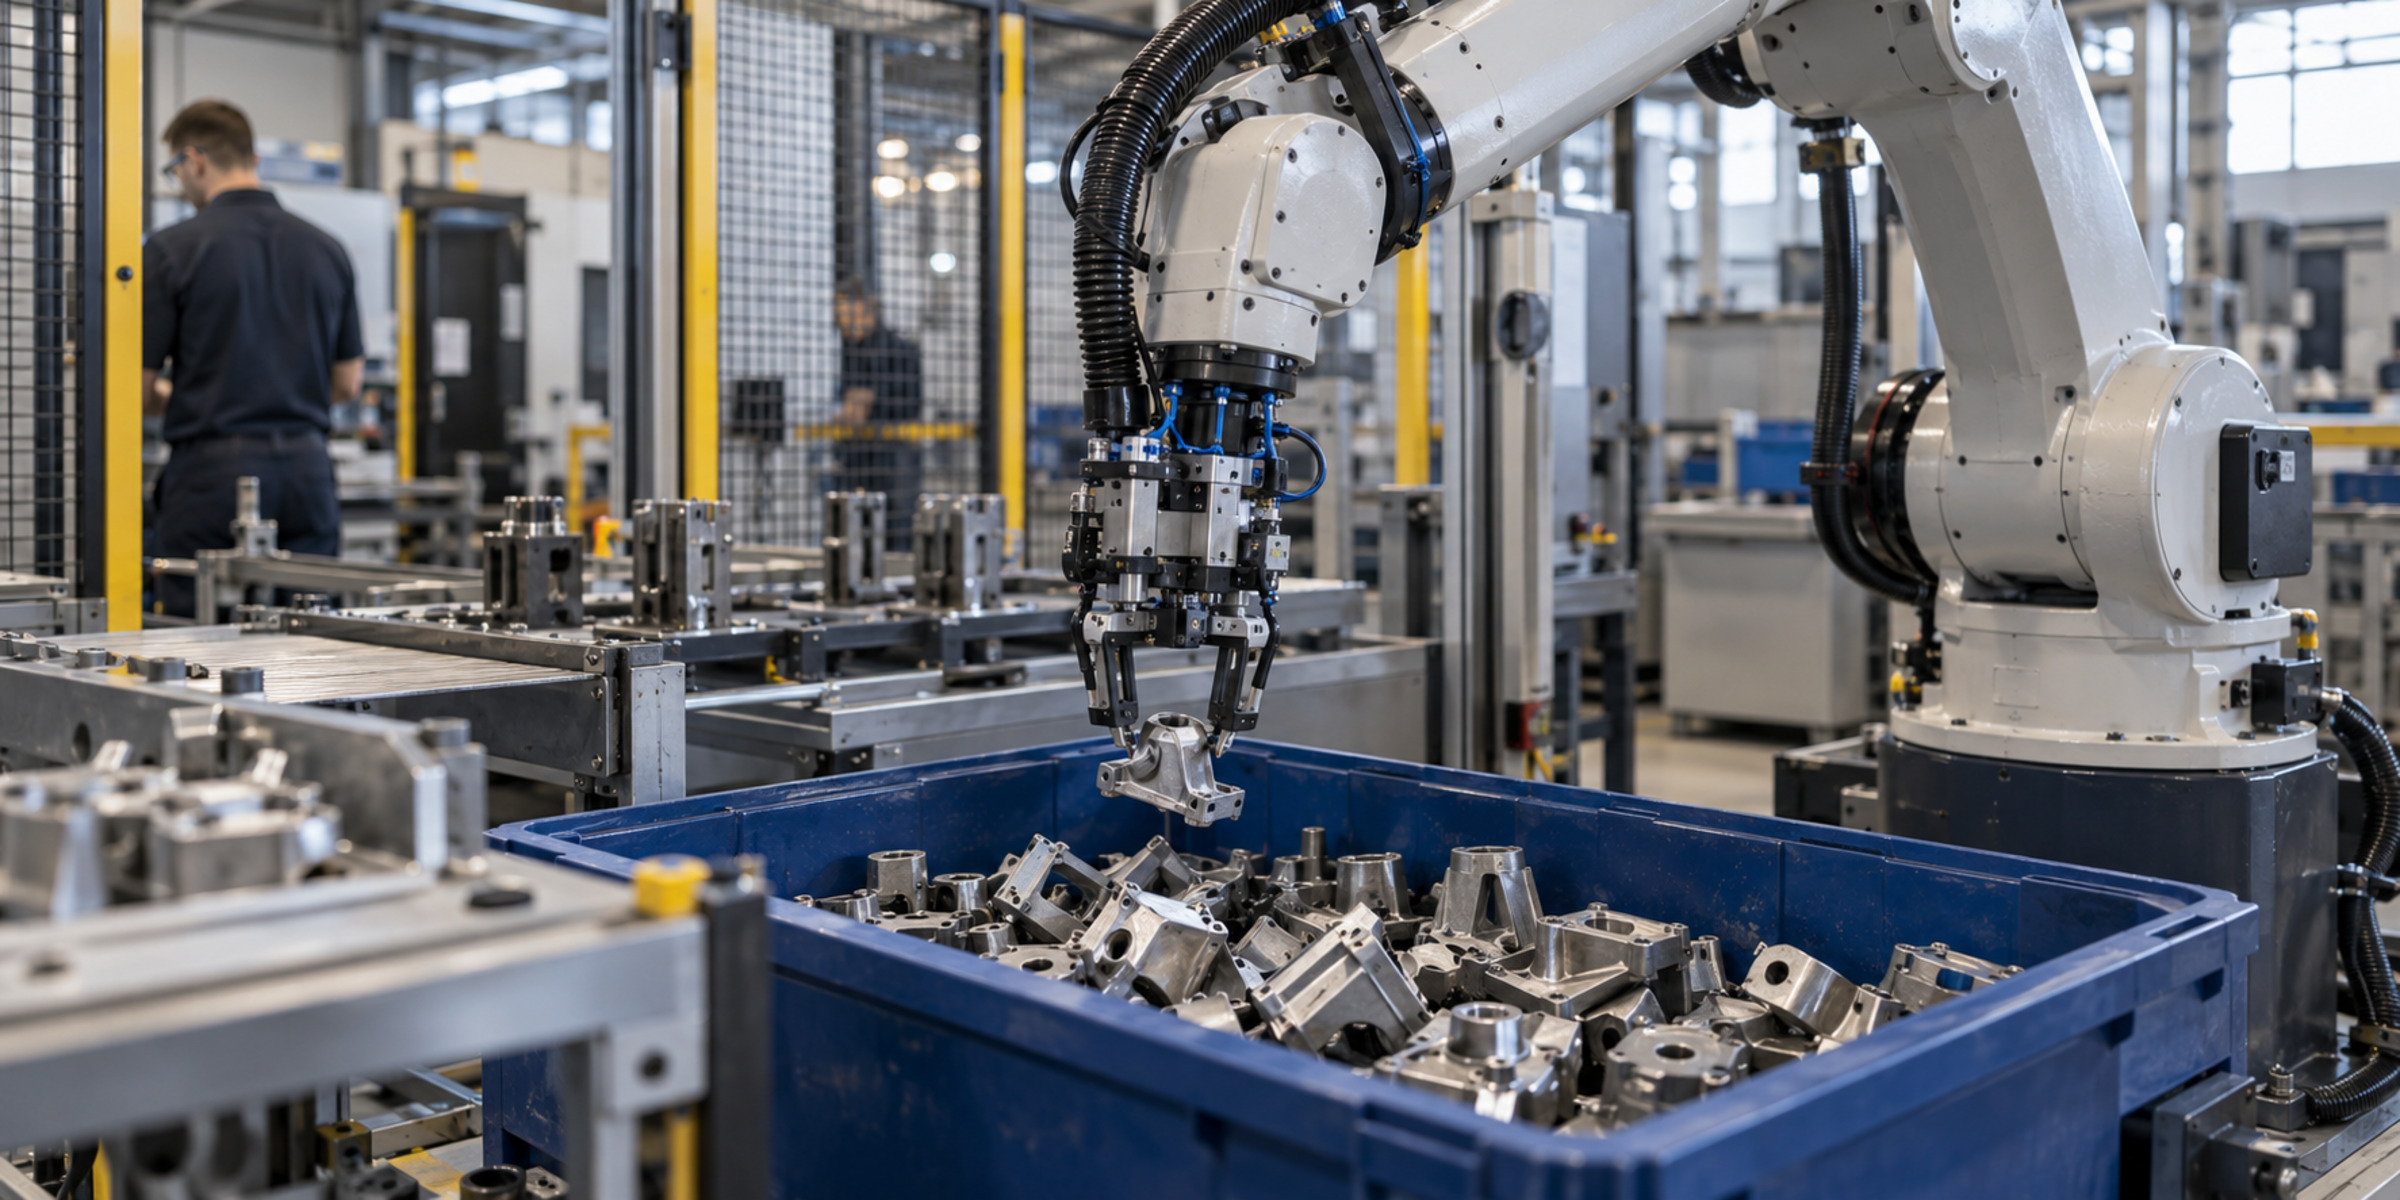
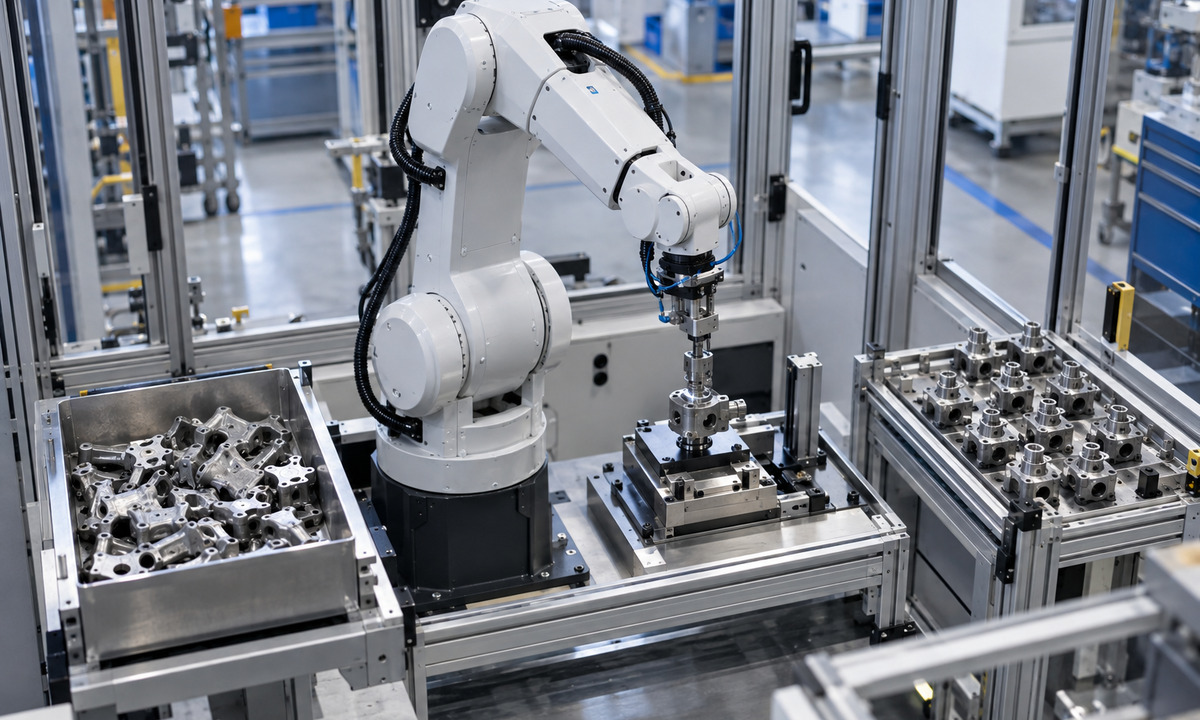
Bringing vision, grasping and motion control into one coordinated cycle, so a robotic cell can handle greater part variability with a clearer path from lab validation to industrial deployment.
The challenge went beyond recognizing an object. The cell had to perceive, grasp and move irregular components consistently, while reducing architectural complexity and limiting deployment risk.
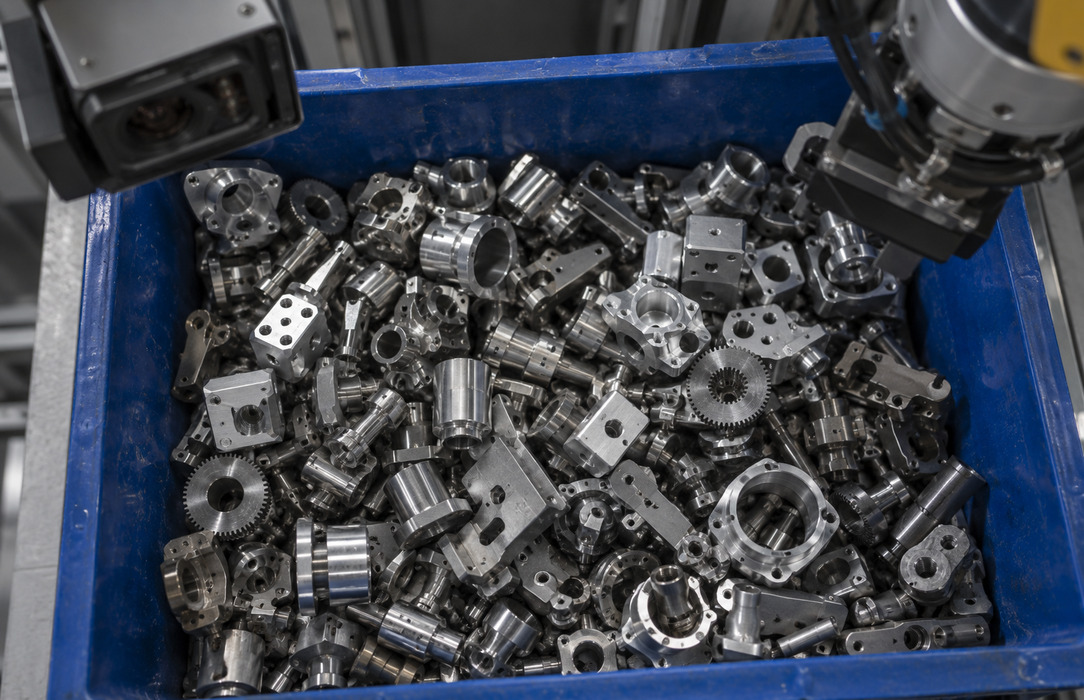
Small metallic parts arrived in different shapes, orientations and levels of occlusion. The initiative required robust pose estimation that could adapt to new variants without starting each model from scratch.
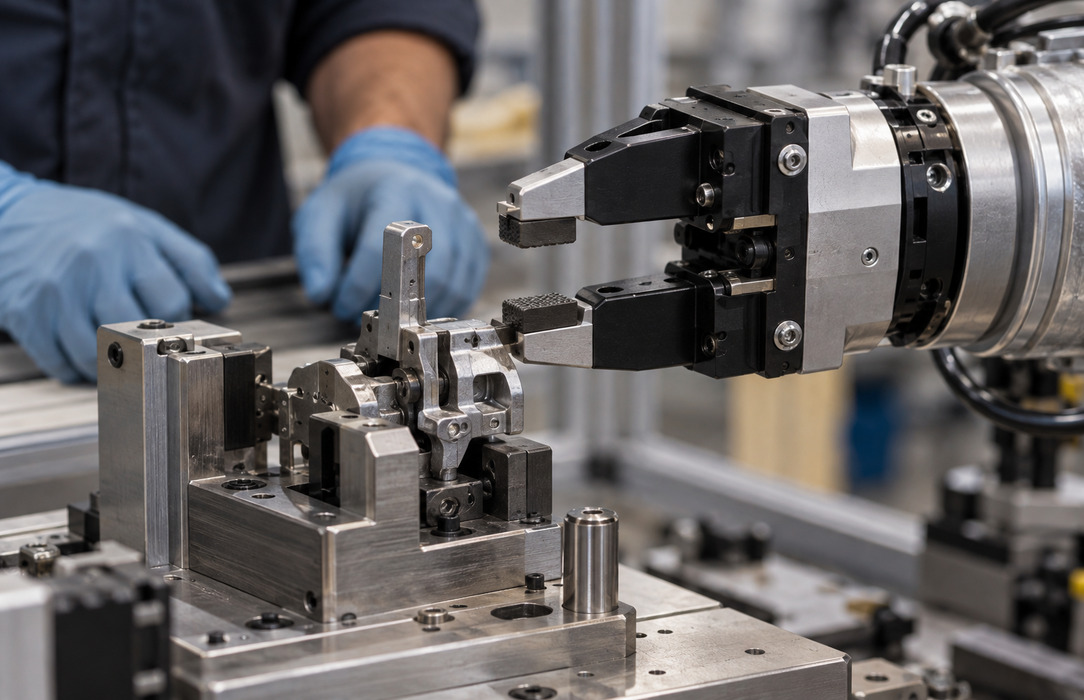
Pose alone was not enough. The gripper strategy had to accommodate complex geometries, including a slider body and puller, and support more stable handling across the cycle.
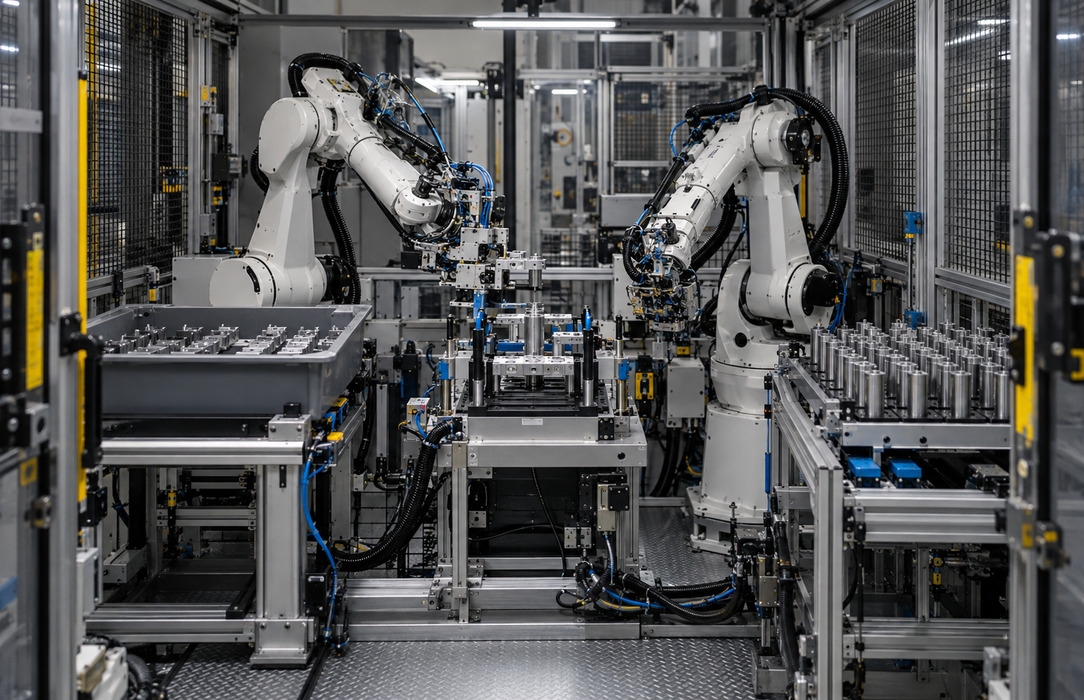
The existing flow used two robotic arms for the full activity. The target architecture needed one robot to execute both steps, with coordinated task logic and cycle management.
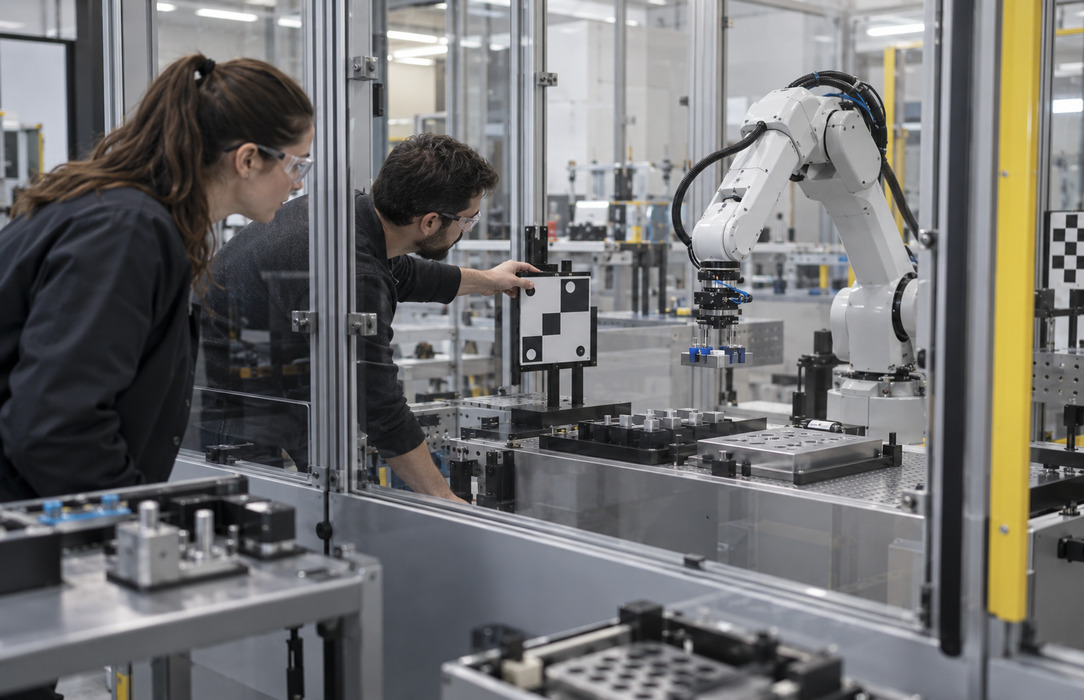
Physical trial-and-error during commissioning could increase integration effort and disrupt production. The solution therefore required high-fidelity simulation and iterative laboratory testing before shop-floor integration.
NTT DATA connected the virtual model, perception models, gripper strategy and cycle-control software into an end-to-end approach, then integrated and tested it in a laboratory environment.

Fine-tuned foundation pose-estimation models on target components, using a one-shot approach to accelerate adaptation to new variants.
Extended the approach to more complex items, including the slider body and puller, and tuned the gripper strategy around their geometry.
Developed task execution and cycle management for the complete pick-and-place process, optimizing the control logic for a single-robot architecture.
Built a high-fidelity simulation of the robot, gripper and parts with realistic visual and physical behavior, then integrated and validated the solution through iterative laboratory demonstrations and test-and-tune sessions.
The initiative established an industrialization-ready foundation made up of reusable digital-twin assets, control software and a lab-validated technical roadmap. It supports lower-effort variant onboarding, fewer physical iterations before deployment and a simpler cell architecture. The source also identifies potential gains in picking stability, availability and scrap reduction; these outcomes remain subject to confirmation with production data and an agreed measurement baseline.
success stories
