Autonomous Robotic Arm with Digital Twin
On plated metal surfaces, a defect can be almost imperceptible and still make a component unacceptable. A luxury fashion manufacturer needed to move beyond a largely manual post-plating inspection process that demanded significant labor, was difficult to scale and left defect judgment exposed to operator and shift variability. NTT DATA designed and implemented an Intelligent Vision solution tailored to the product and process, combining use-case design, computer vision and an industrial inspection station prepared for repeatable, low-latency operation.
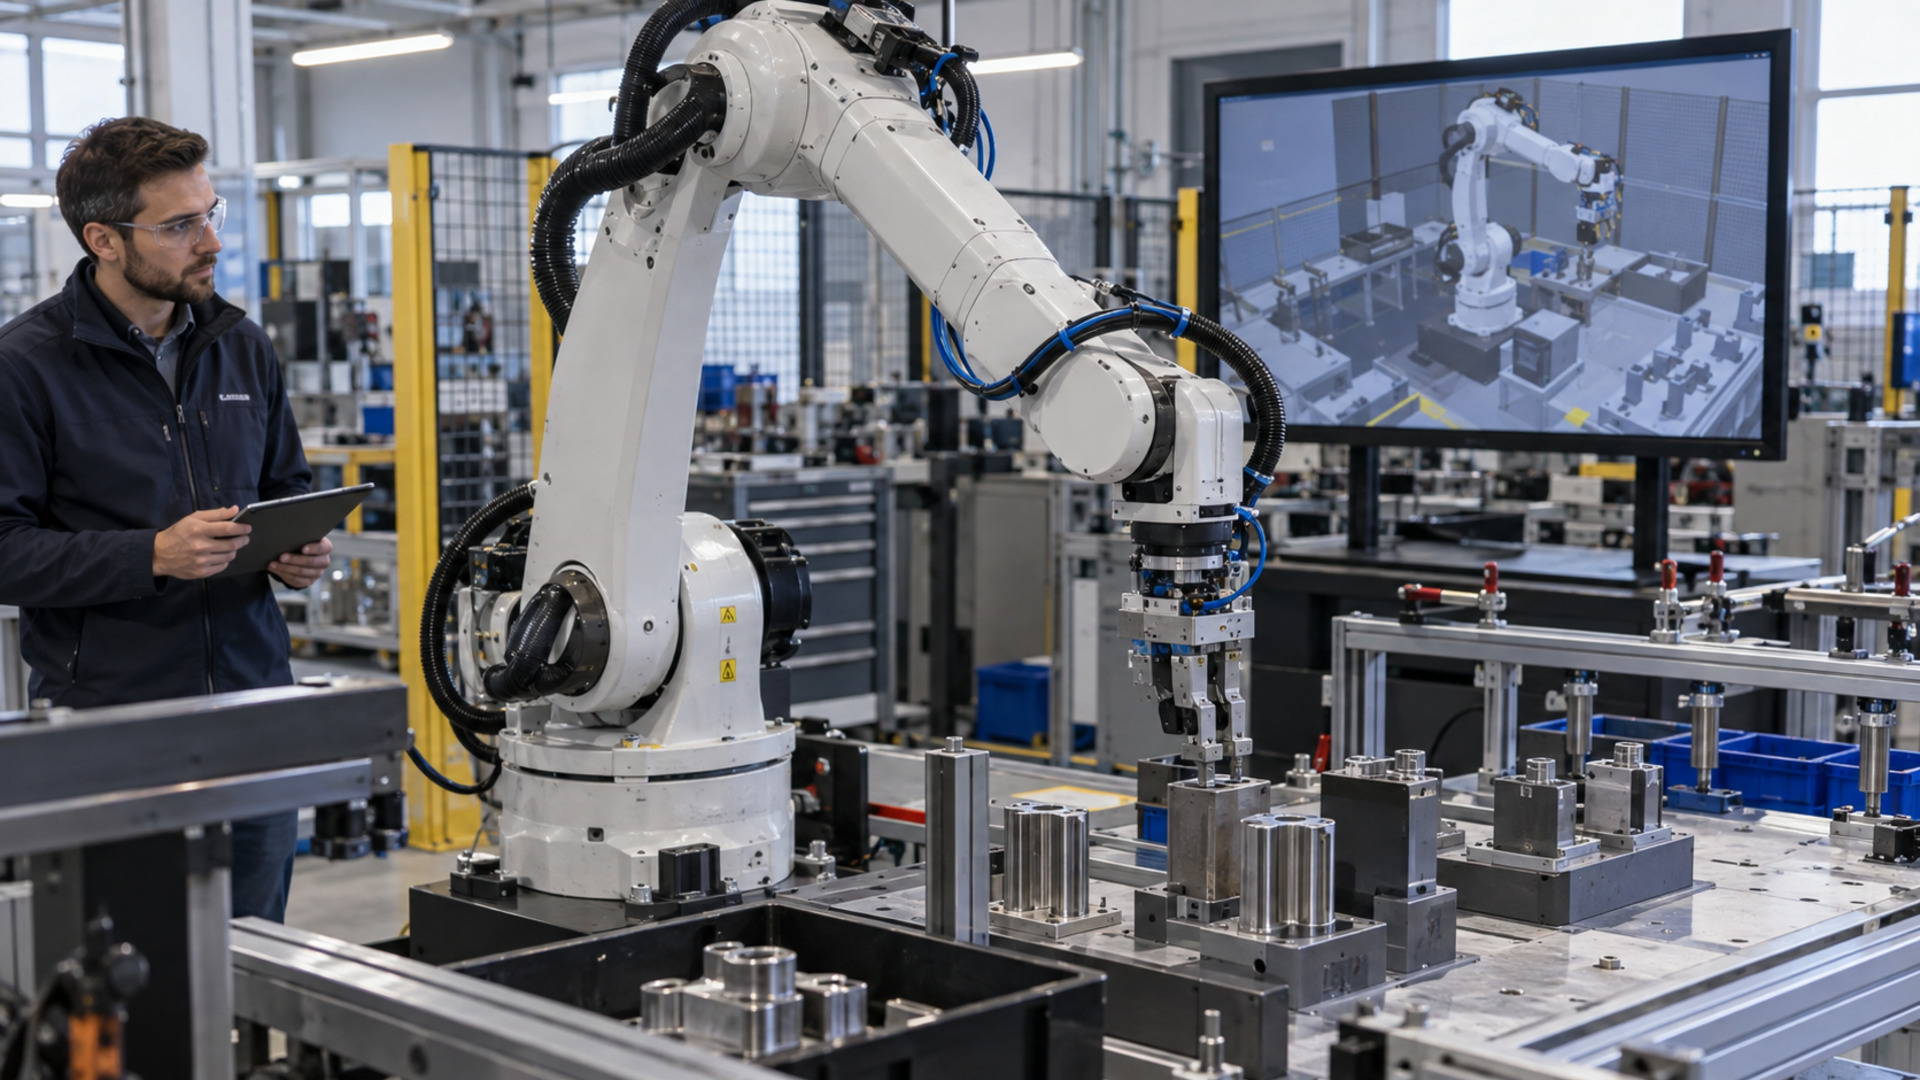
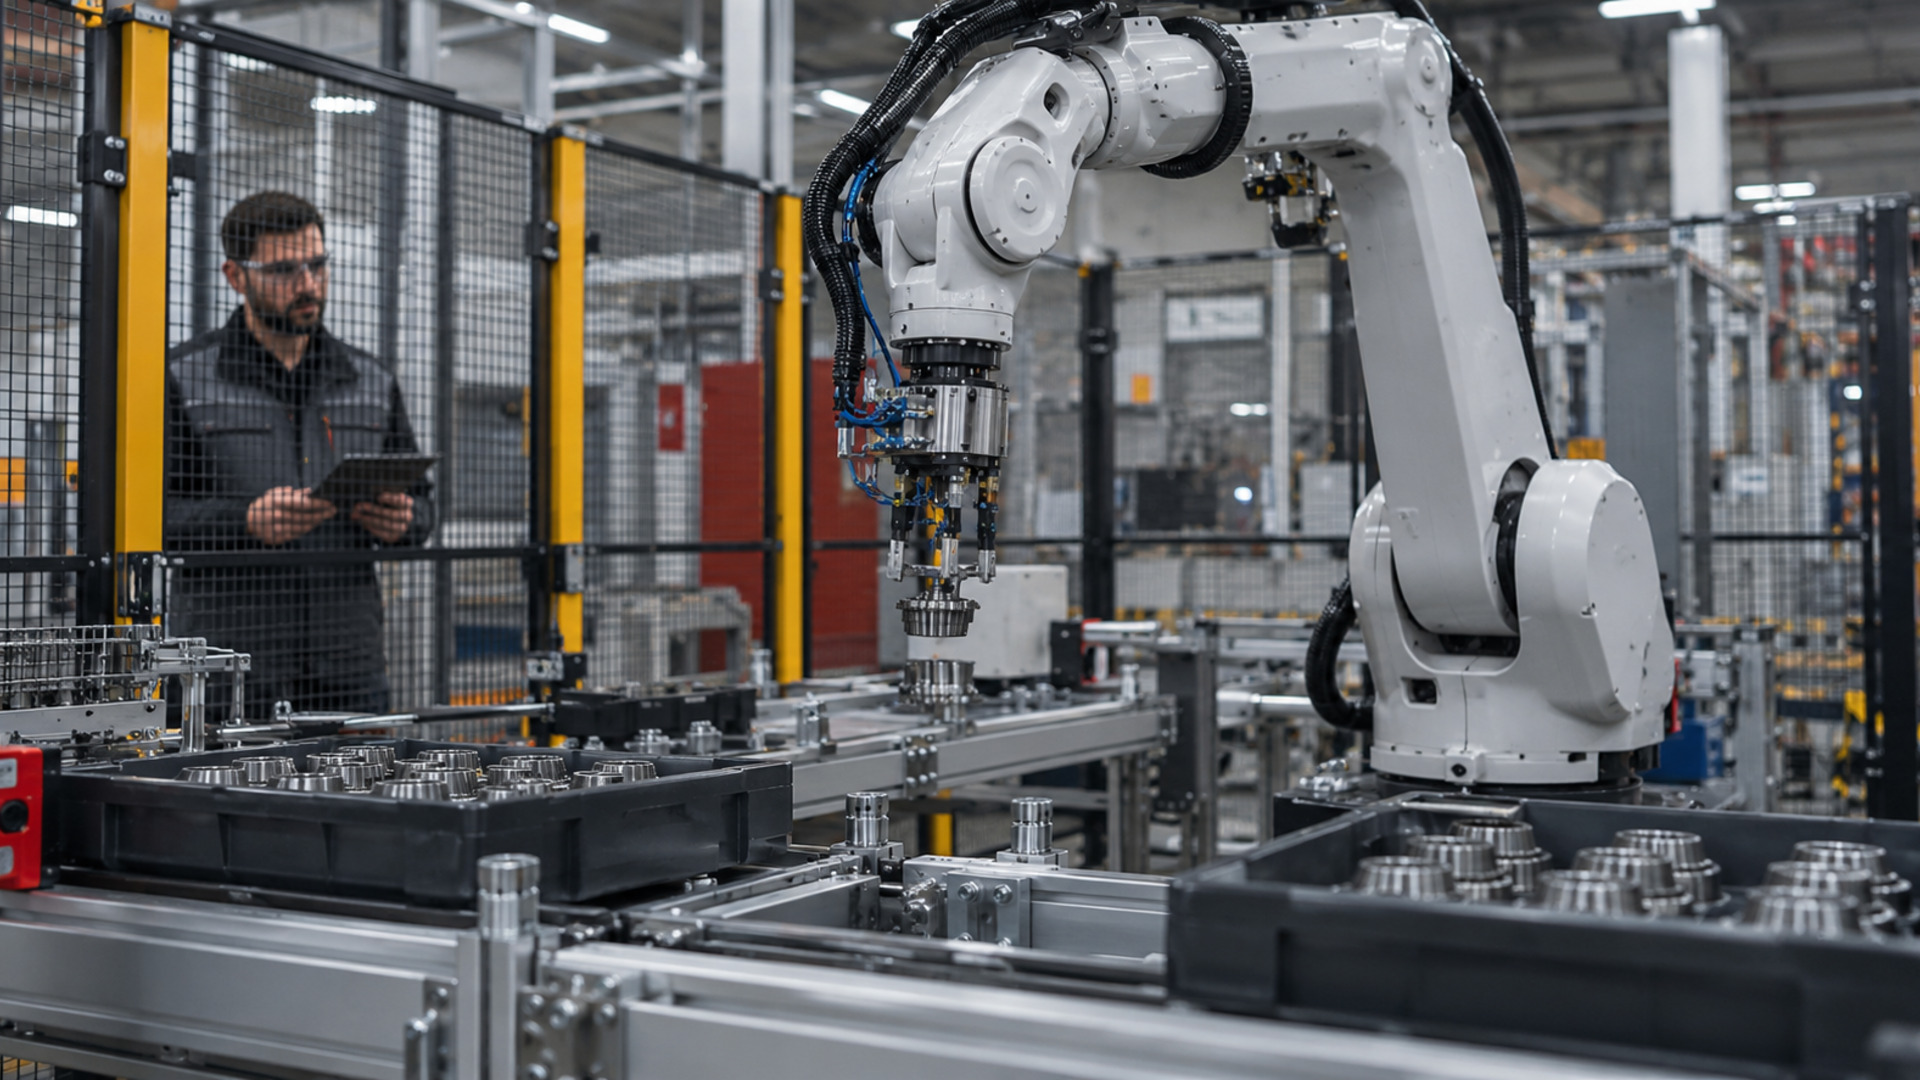
Articulated robot arm performs a pick-and-place task in a fenced manufacturing cell while an engineer observes from a safe distance.
Multi-side coverage
Inspection across all relevant surfaces
Defined quality signals
Accuracy, false rejects and false accepts
Edge-ready inference
Architecture prepared for low-latency operation
Defect roadmap
From OK/KO to category classification
Engineer compares a physical robotic arm with its matching digital twin during movement validation in an industrial test bay.
Automatic quality inspection for metal surfaces

Automating the visual inspection process with Computer Vision.

Turning a demanding post-plating quality gate into a more repeatable, scalable and production-ready inspection capability.
Objectives
The initiative set out to automate visual inspection after plating without lowering the aesthetic standards applied to metallic components. The ambition was to reduce dependence on labor-intensive manual checks, limit subjectivity in defect judgment and establish a consistent inspection flow across the relevant faces of each component. The design also needed to operate under real production conditions, including reflective materials, lighting variation and micro-defects, while creating a measurable basis for assessing accuracy, false rejects, false accepts and robustness.
Opportunity
A reliable first-stage OK/KO decision creates a path toward a richer quality intelligence layer. The stated roadmap is to classify the four or five most relevant defect categories, giving the manufacturer a more structured view of recurring surface issues and a clearer basis for process improvement. The edge-ready design also opens the possibility of low-latency deployment on the production line and integration with existing handling or automation where available. These next steps remain opportunities until their deployment and performance are confirmed.
Making aesthetic quality repeatable at production scale

The inspection challenge went beyond finding visible flaws. It required a dependable quality decision across reflective, multi-face components, under conditions where people, lighting and production volume could all influence consistency.
Key Challenges
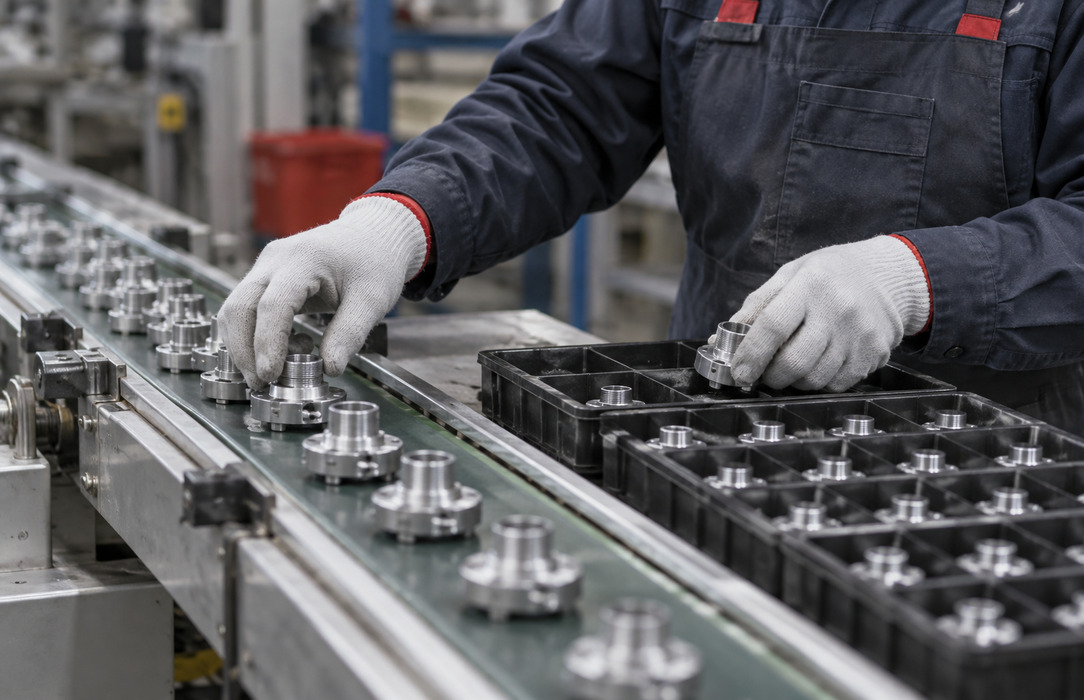
Gloved worker manually transfers machined metal components from a conveyor into trays in a manufacturing workstation.
1: Manual effort at volume
Post-plating quality control relied largely on manual visual inspection, creating high labor effort and limited scalability as production volumes increased.
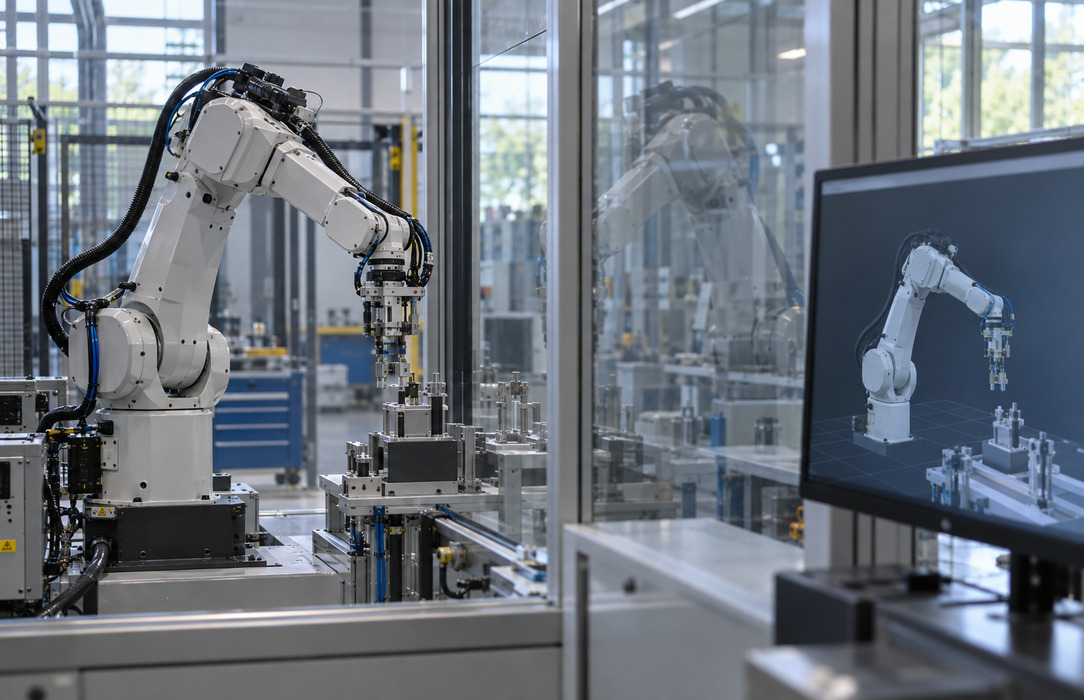
Physical robotic arm and its reflected geometry align beside a monitor showing the corresponding digital model in an industrial lab.
2: Variable defect judgment
Assessment could vary by operator or shift, increasing the risk of inconsistent defect capture and human error.
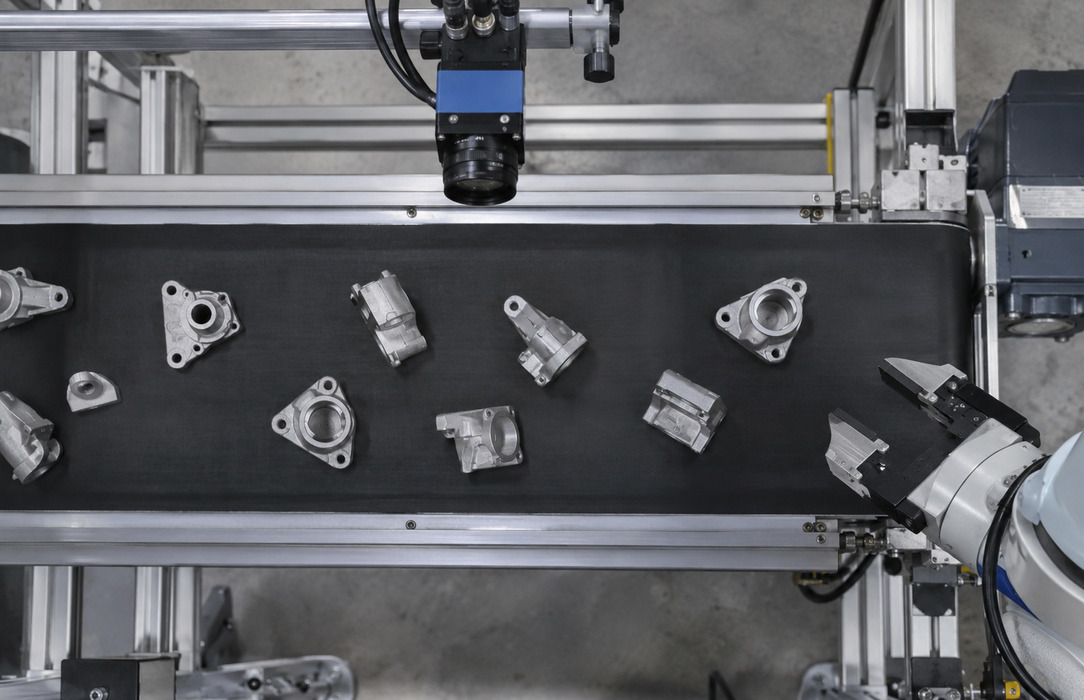
Overhead industrial camera monitors irregular metal parts on a conveyor while a robotic gripper waits to select an object.
3: Reflective, multi-face surfaces
The inspection had to identify micro-defects on plated, reflective materials while covering every relevant face of the component.
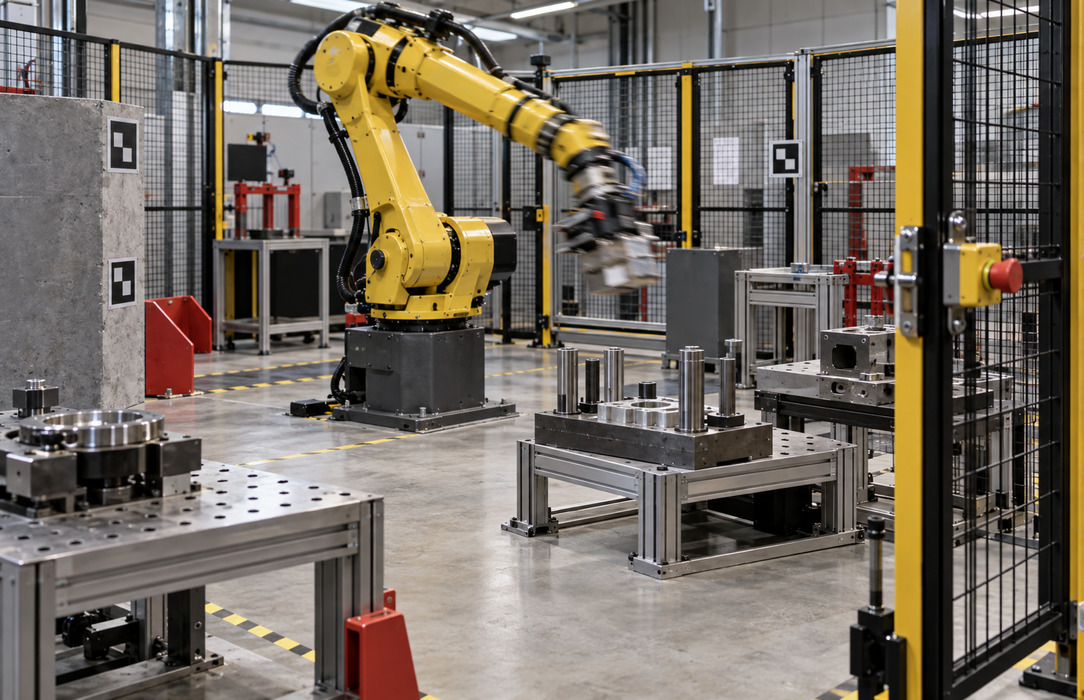
Industrial robot moves between calibration fixtures in a guarded test cell used to validate its path before deployment.
4: Production-ready inspection
The initiative needed a repeatable, low-latency design that could reduce inspection time and cost pressure without compromising quality, and connect with existing handling or automation where available.
Solution
An Intelligent Vision system designed around the product, process and quality decision

NTT DATA combined shopfloor analysis, a KPI-led computer vision approach and a purpose-designed inspection station. The resulting architecture links image acquisition, controlled illumination and edge-ready inference around the realities of plated metal components.

check icon
Use-case framing and measurable quality criteria

Shopfloor analysis defined the target inspection flow, dataset strategy, labeling rules and the KPIs needed to evaluate accuracy, false rejects, false accepts and robustness.

check icon
Computer vision for consistent decisions

The solution applies visual defect detection to support an initial OK/KO decision. The selected approaches were evaluated for real production conditions, with a roadmap toward classification of the four or five most relevant defect types.

check icon
Multi-camera acquisition and controlled illumination

A multi-camera setup captures multiple faces of the component, while controlled lighting is designed to stabilize image quality on reflective materials and make small surface anomalies more observable.

check icon
Edge-ready industrial architecture

The inspection station is prepared for low-latency inference and easier production-line integration, including connection with existing handling or automation where available.

Impact
A foundation for more consistent quality decisions

The implemented Intelligent Vision solution provides a structured foundation for moving post-plating inspection from a predominantly manual activity toward a repeatable, measurable and scalable process. Its multi-face acquisition, controlled illumination and edge-ready design support more consistent defect assessment and future line integration. The source does not provide validated production results, so no reduction in inspection time, labor effort, cost, false rejects, false accepts or defect escape rate is claimed.

Drag