


- All Foundries

- Commodity Management & Trading

- Customer & Marketing Strategy

- Digital Engineering

- Station Studio

- Supply Chain & Industry 5.0
- Sustainability

- Physical AI

- Next-Generation Infrastructure

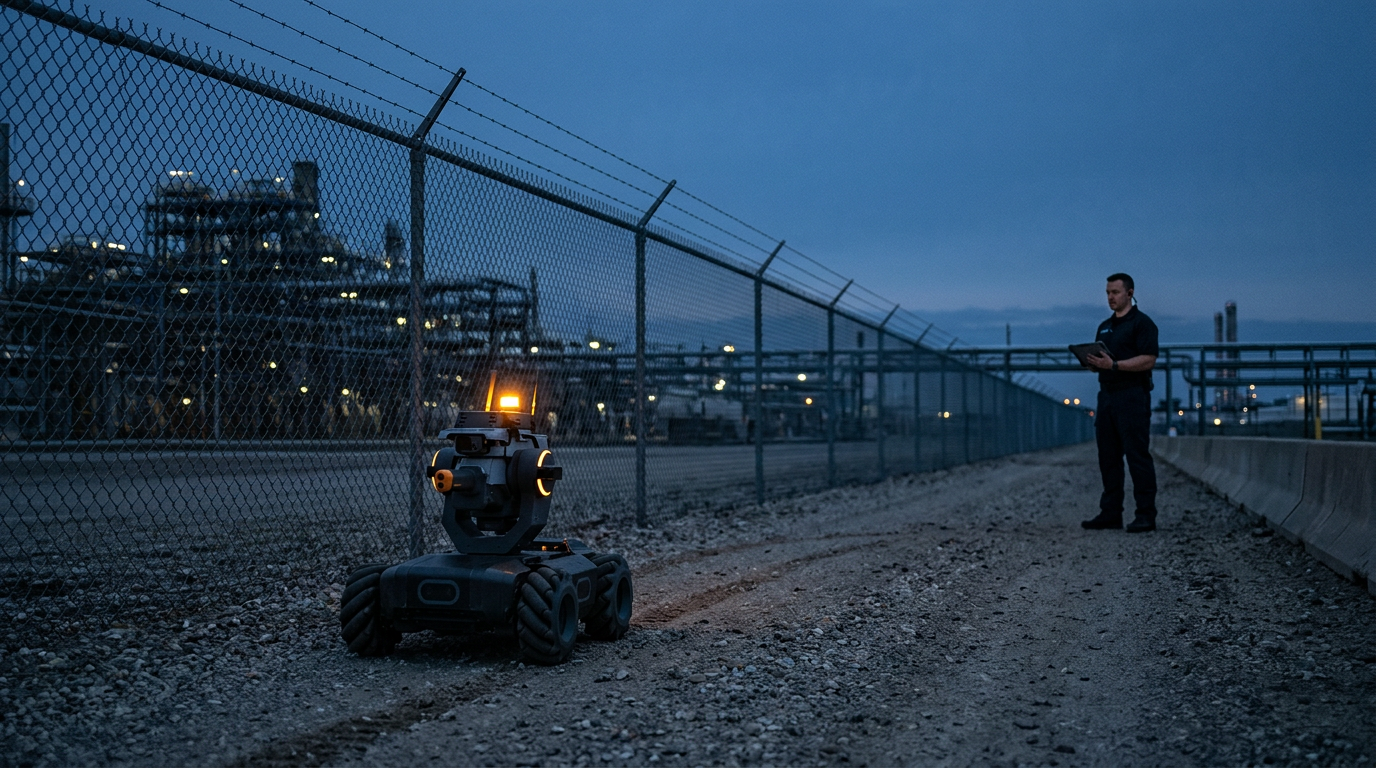
Security and resilence through advanced robotics
Sensitive infrastructure can contain blind spots, hazardous zones and changing conditions that are difficult to supervise continuously with fixed surveillance alone. A European-funded critical infrastructure initiative addresses this by combining autonomous robotics with AI-based perception and real-time reasoning, creating mobile systems that can inspect, interpret and support response while preserving safety and operational continuity.
Mobile robotic systems add a physical dimension to surveillance, allowing threat awareness to follow the areas where conditions and risk are changing.

Autonomous platforms can patrol sensitive areas and extend monitoring beyond locations that fixed cameras or stationary systems can observe continuously.
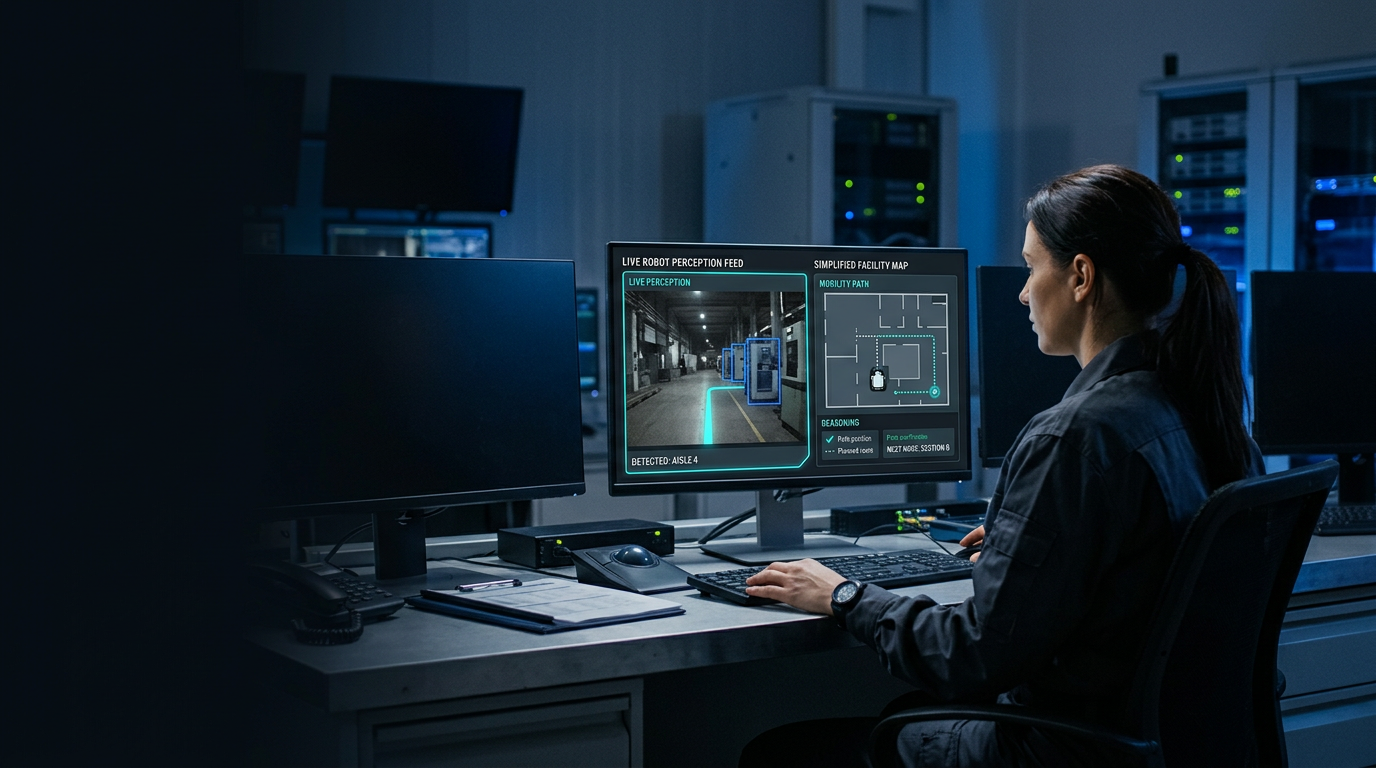
Computer vision and anomaly detection help surface unusual conditions while real-time reasoning adds context to what the robotic system is observing.
Inspection and intervention activities can be shifted toward autonomous platforms when direct access would place personnel in potentially dangerous situations.
Benchmarking and field experimentation provide a basis for evaluating robotic and AI performance before broader long-term deployment.
How NTT DATA helps
Computer vision, anomaly detection and situational awareness capabilities are developed specifically around the security conditions the robotic system must recognize.
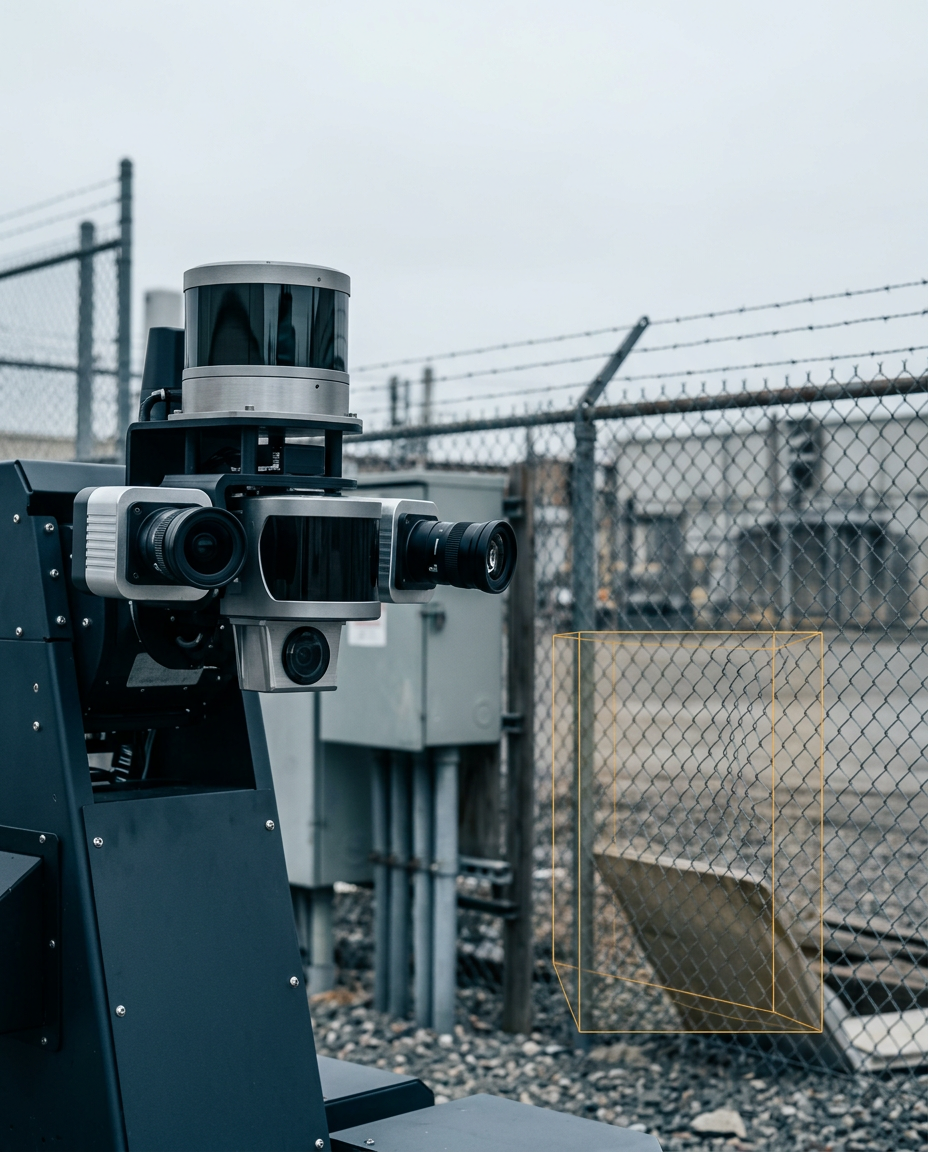
Decision-making and real-time processing are placed onboard the robotic system so detected conditions can be assessed during the mission itself.
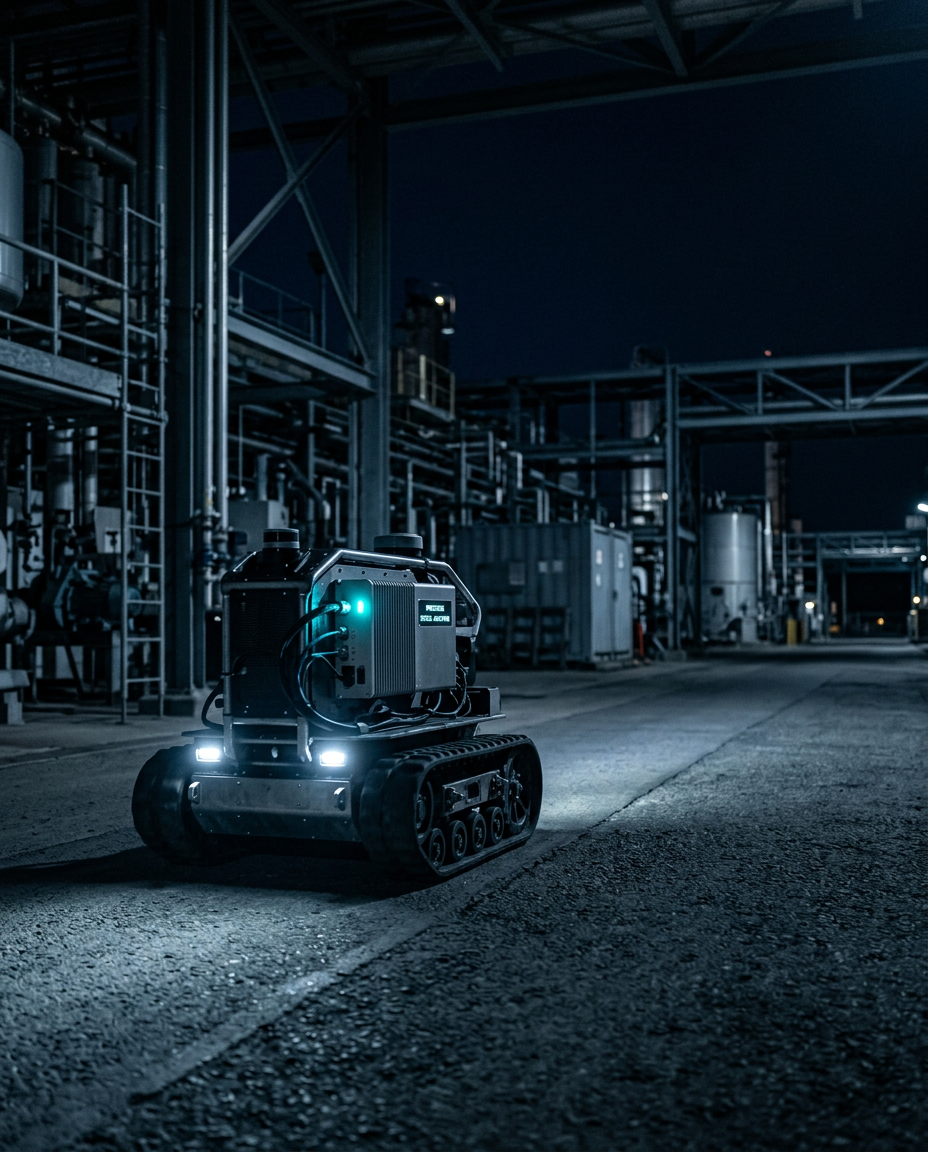
NTT DATA scouts and benchmarks robotic platforms and AI models against the operational demands of autonomous inspection and security response.
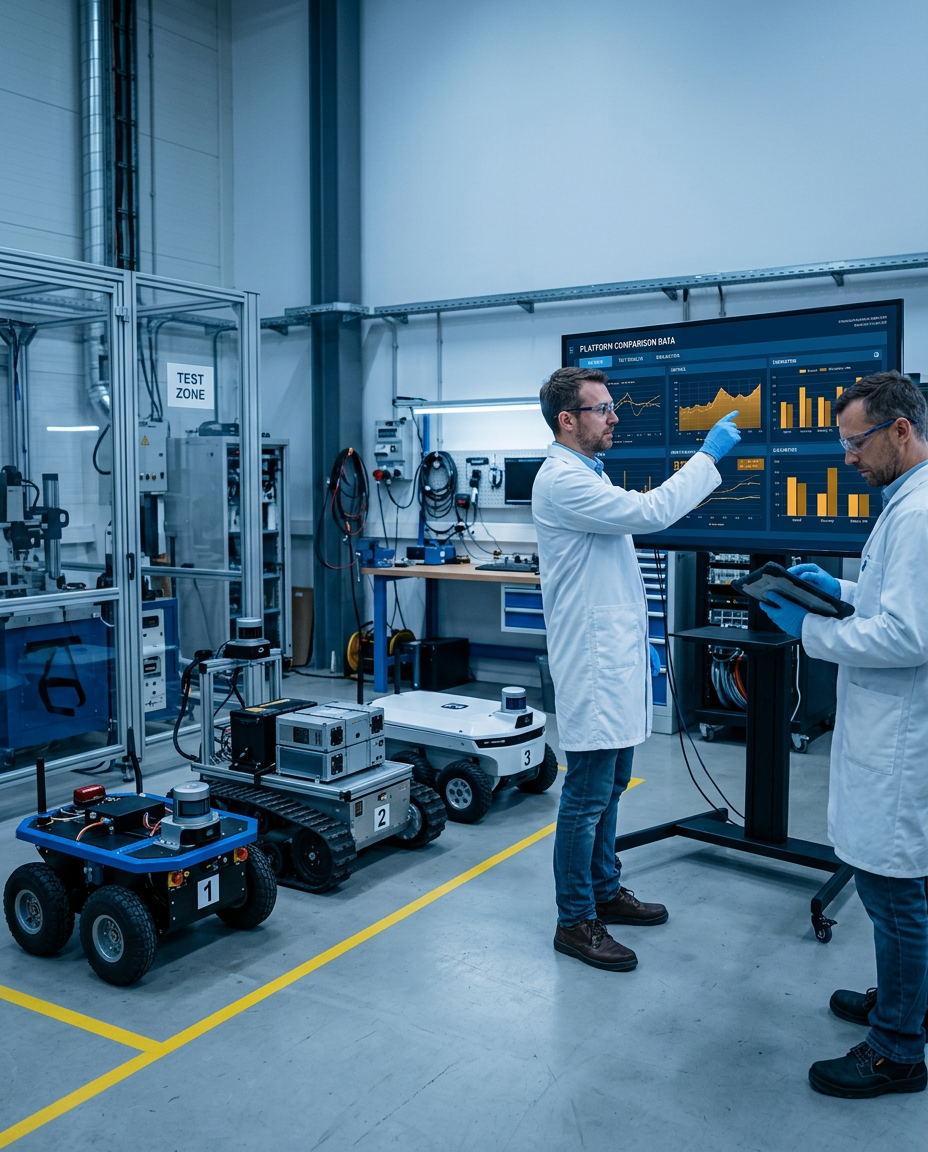
Inspection and intervention strategies are exercised in managed settings to reveal limitations before the system is introduced into more demanding environments.
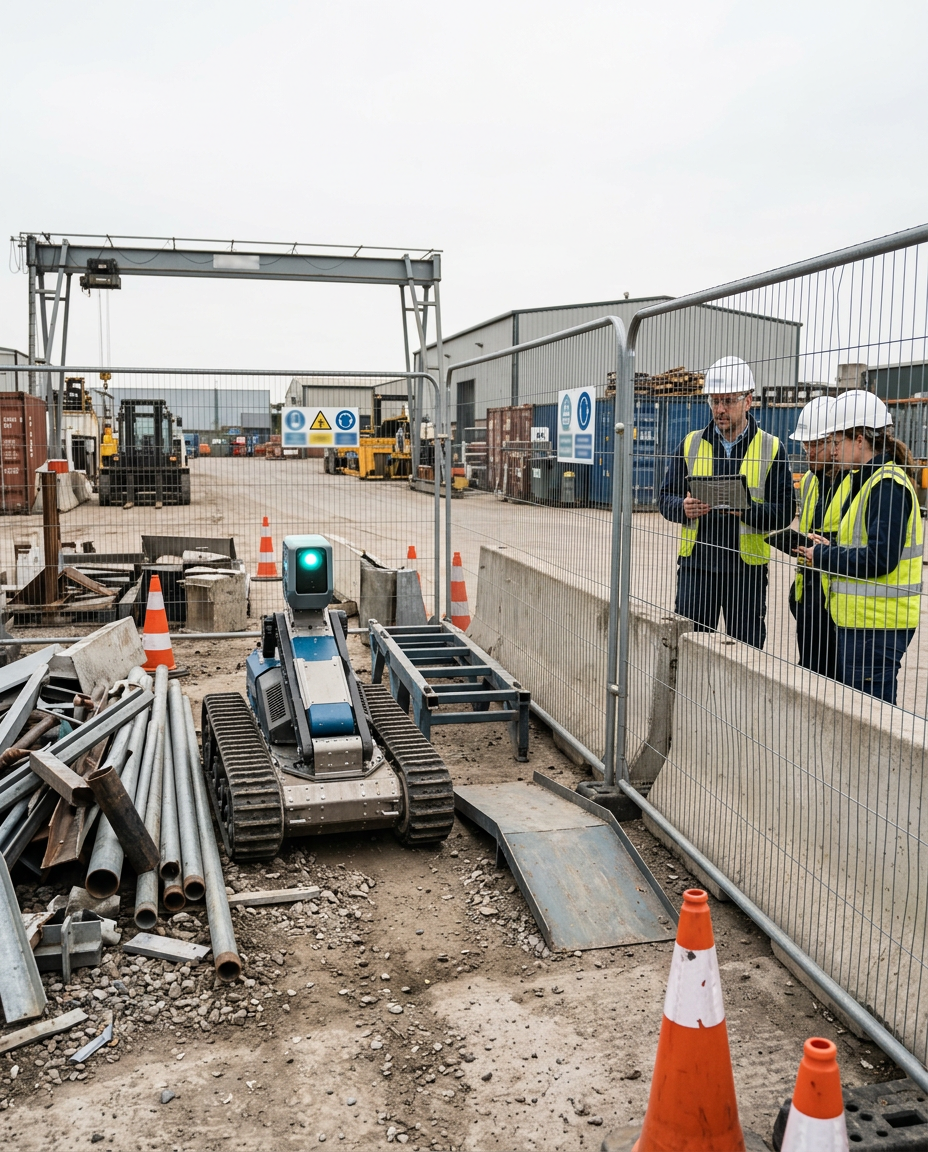
Field testing measures how perception, autonomy and robotic behavior perform under actual infrastructure conditions rather than relying only on laboratory results.
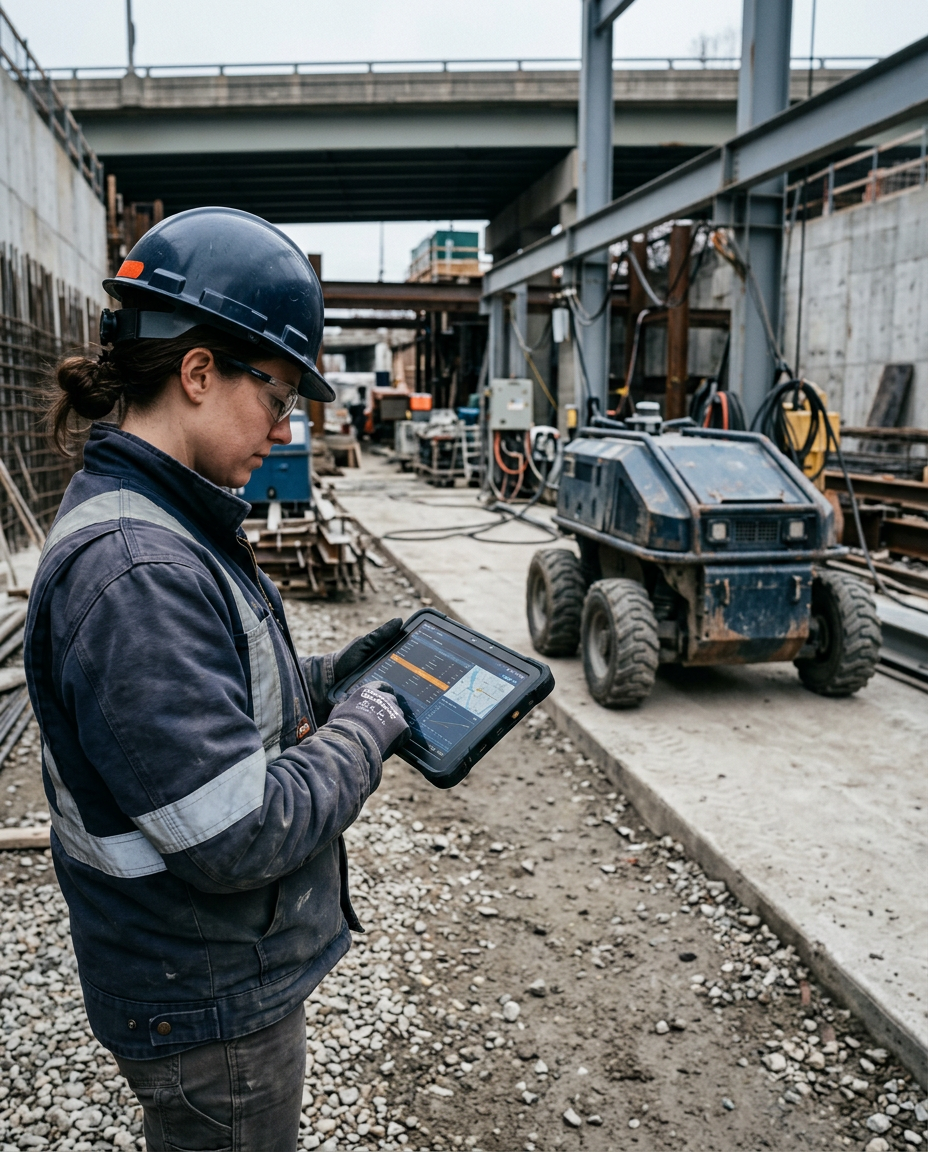
The available evidence is qualitative, centered on infrastructure protection, situational awareness, reduced human risk exposure and scalability rather than quantified percentage gains.
Autonomous surveillance and inspection can extend protection across sensitive infrastructure by maintaining mobile observation and supporting detection of conditions that may require response.
Real-time visual analysis and anomaly detection provide additional situational information that can help operators understand what is occurring across protected areas.
Robotic inspection and intervention can limit the need for people to enter hazardous locations while maintaining continuity of security and monitoring activities.
Scouting, benchmarking, controlled pilots and field testing create a progressive validation path for assessing whether autonomous security capabilities are ready for broader use.
Evaluate where robotic perception, onboard reasoning and field-tested autonomy can strengthen infrastructure protection while keeping people farther from hazardous conditions.
