


- All Foundries

- Commodity Management & Trading

- Customer & Marketing Strategy

- Digital Engineering

- Station Studio

- Supply Chain & Industry 5.0
- Sustainability

- Physical AI

- Next-Generation Infrastructure

Automatic quality inspection for metal surfaces
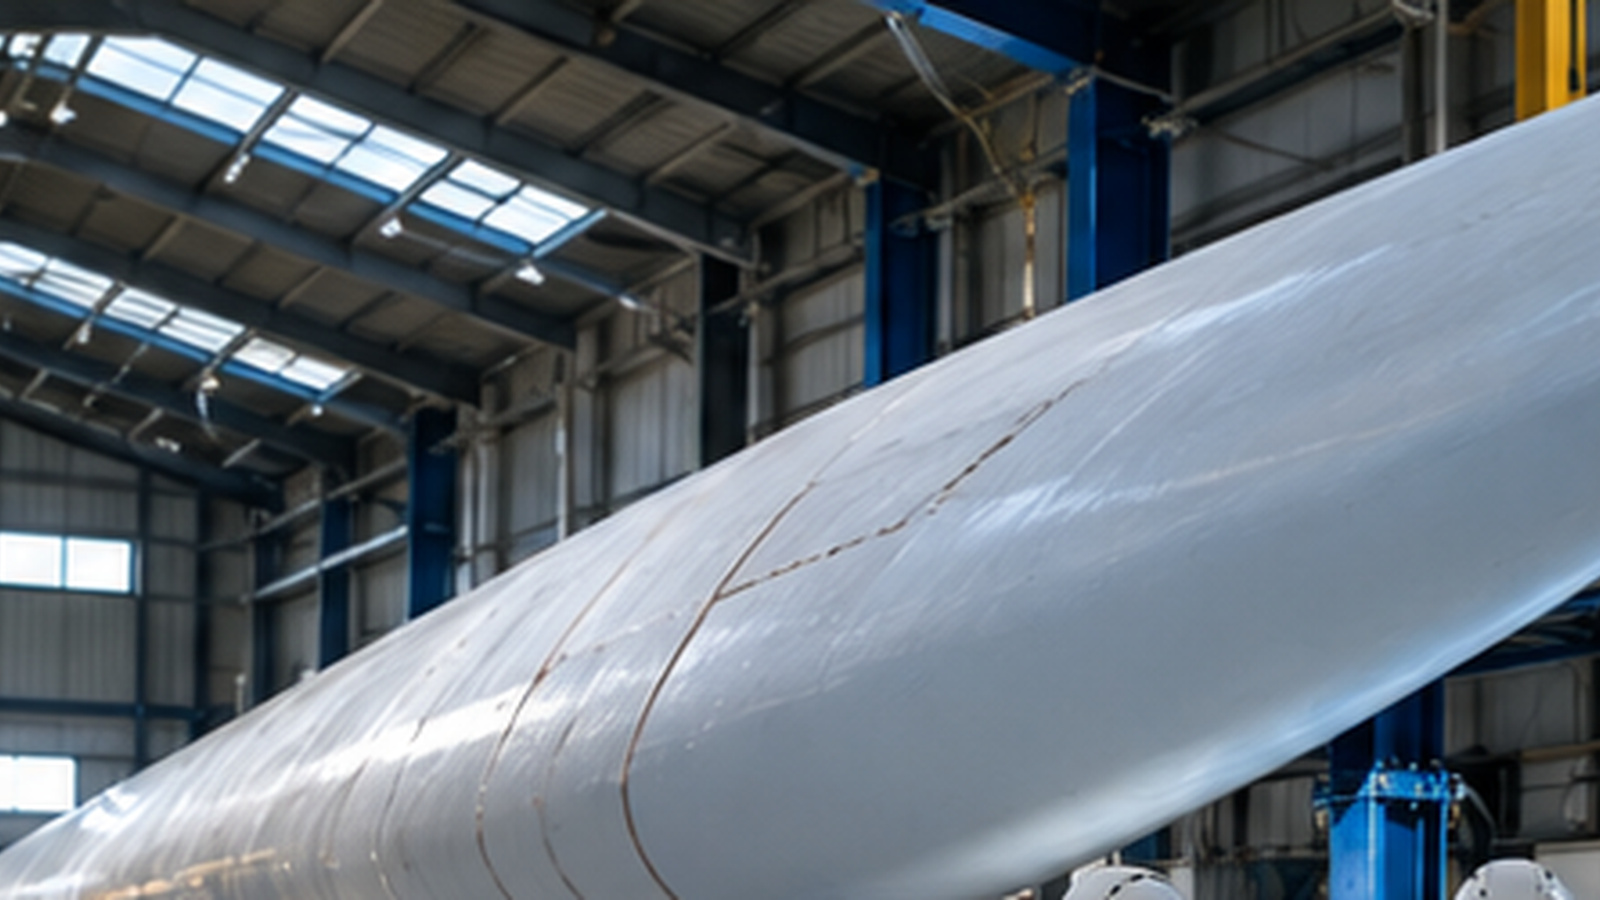
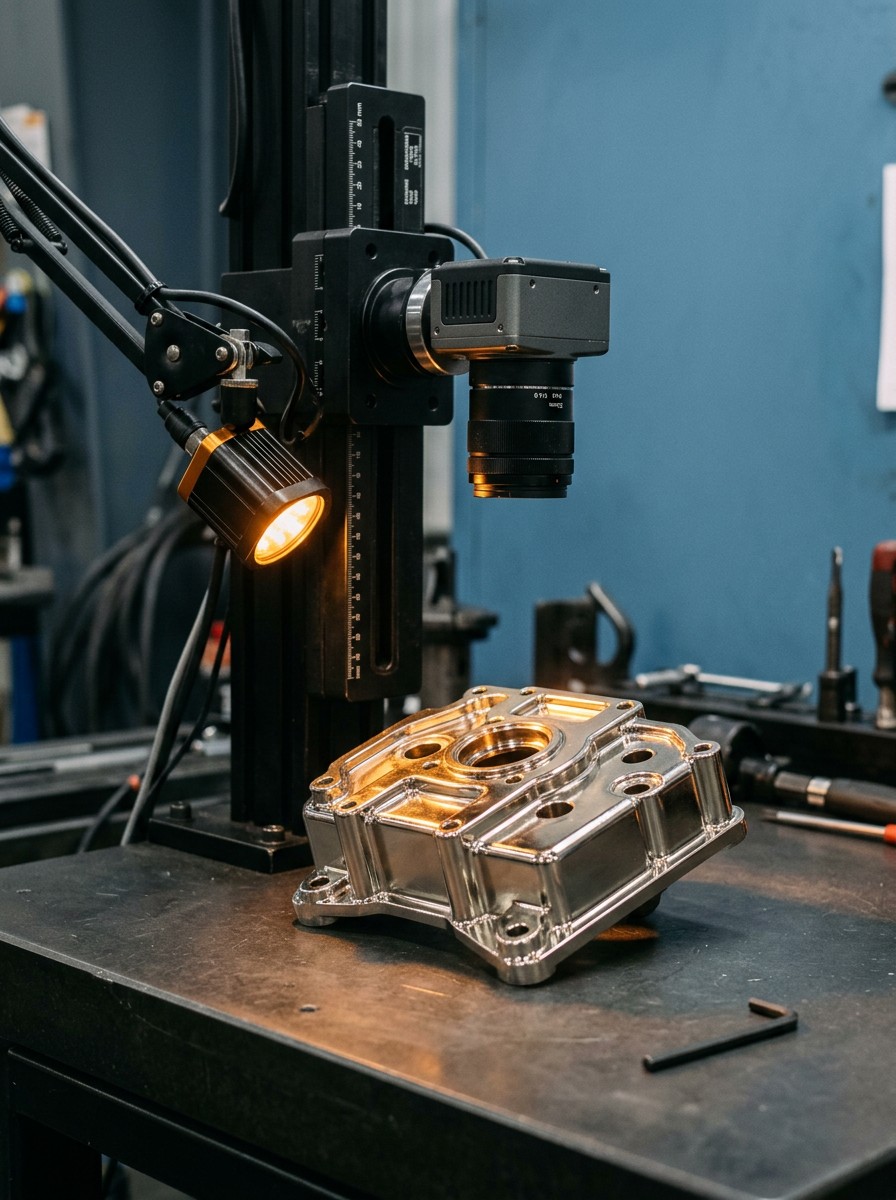
Plated metallic components make visual quality control unusually demanding because reflections, lighting changes and micro-defects can influence what inspectors see. Operator and shift dependency adds further variability, while increasing volumes put pressure on inspection time and labor. An effective automated approach therefore needs stable image acquisition, clearly defined acceptance criteria and computer vision methods validated against real shopfloor conditions.
The business value lies in making surface inspection more consistent, comprehensive and scalable without relaxing strict aesthetic standards.

Standardized image capture and model-based evaluation reduce variation in how operators judge whether plated components meet visual quality requirements.
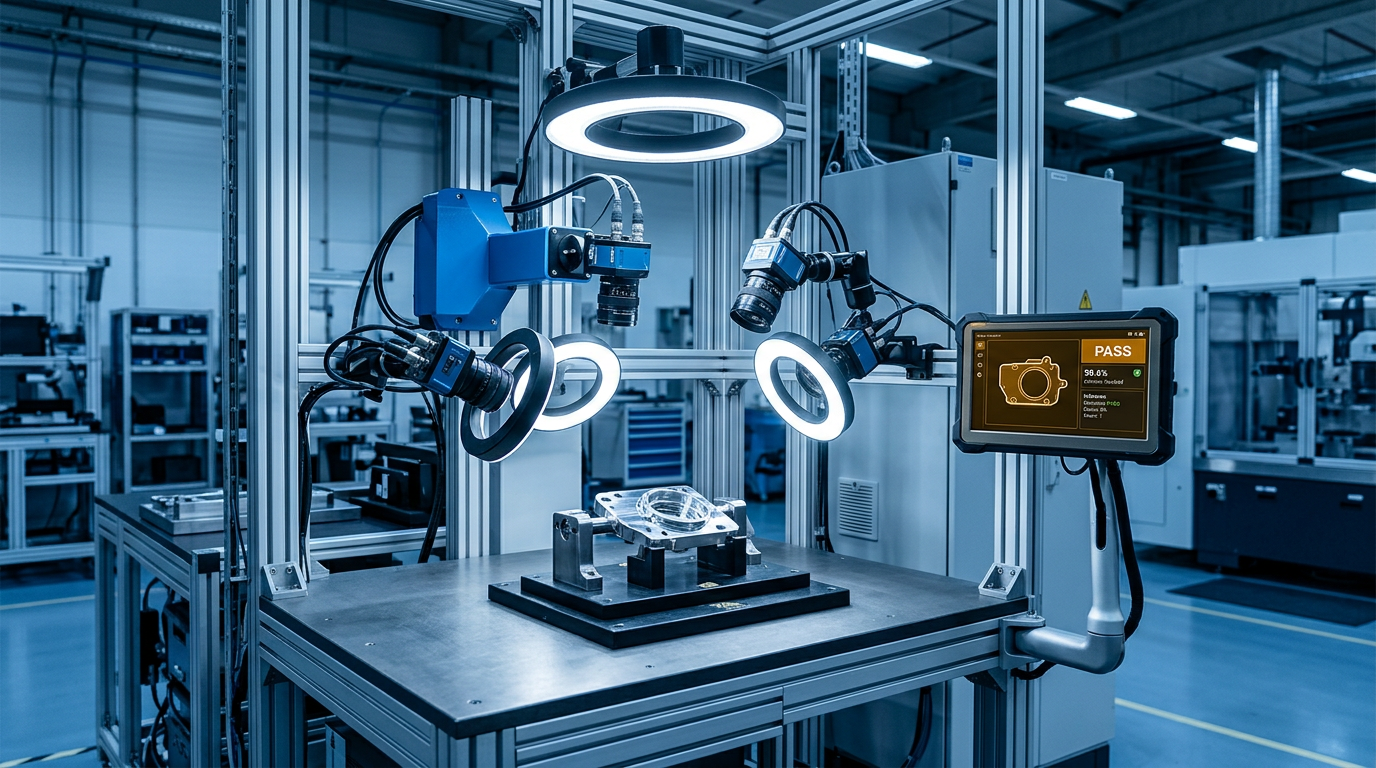
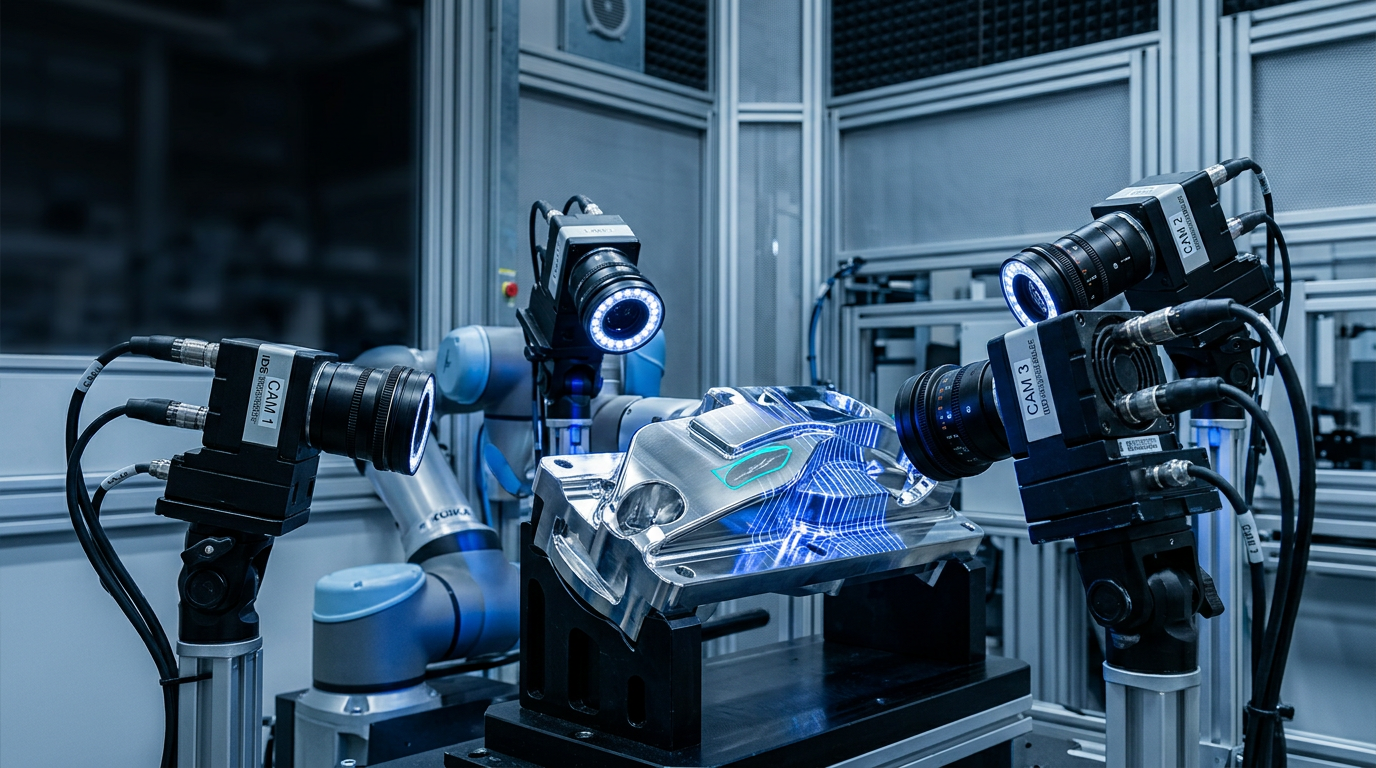
Several camera viewpoints can inspect all relevant component surfaces, reducing the chance that defects remain outside the field of view.
Automated checks can accommodate higher inspection volumes without requiring manual inspection effort to increase at the same rate.
The roadmap supports an initial OK/KO decision and can evolve toward classification of the top four to five relevant defect categories.
How NTT DATA helps
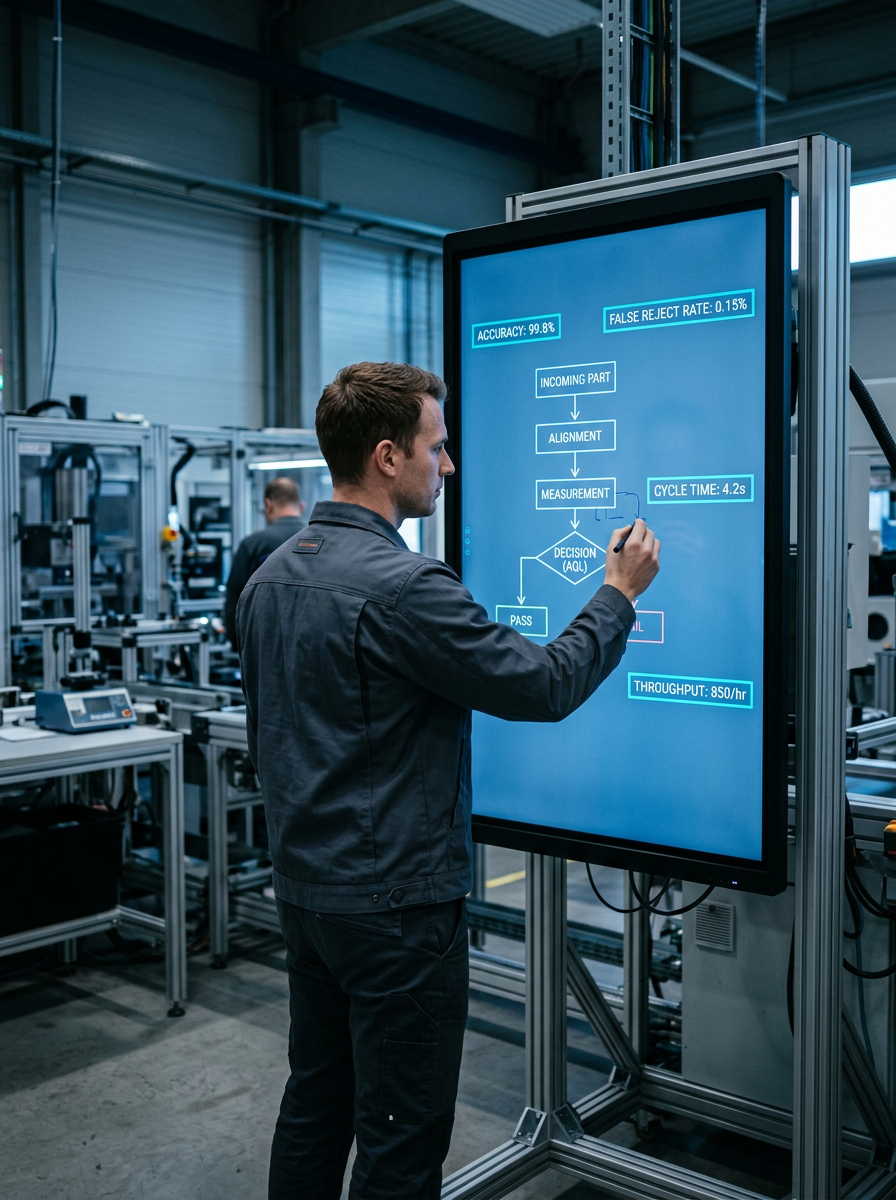
The work begins by defining the target inspection flow and the KPIs that matter, including accuracy, false rejects, false accepts and robustness.
Camera placement and controlled illumination are designed around plated surfaces so image quality remains stable enough for repeatable analysis.
Product characteristics, relevant inspection faces and labeling rules shape the dataset used to teach the system what acceptable and defective surfaces look like.
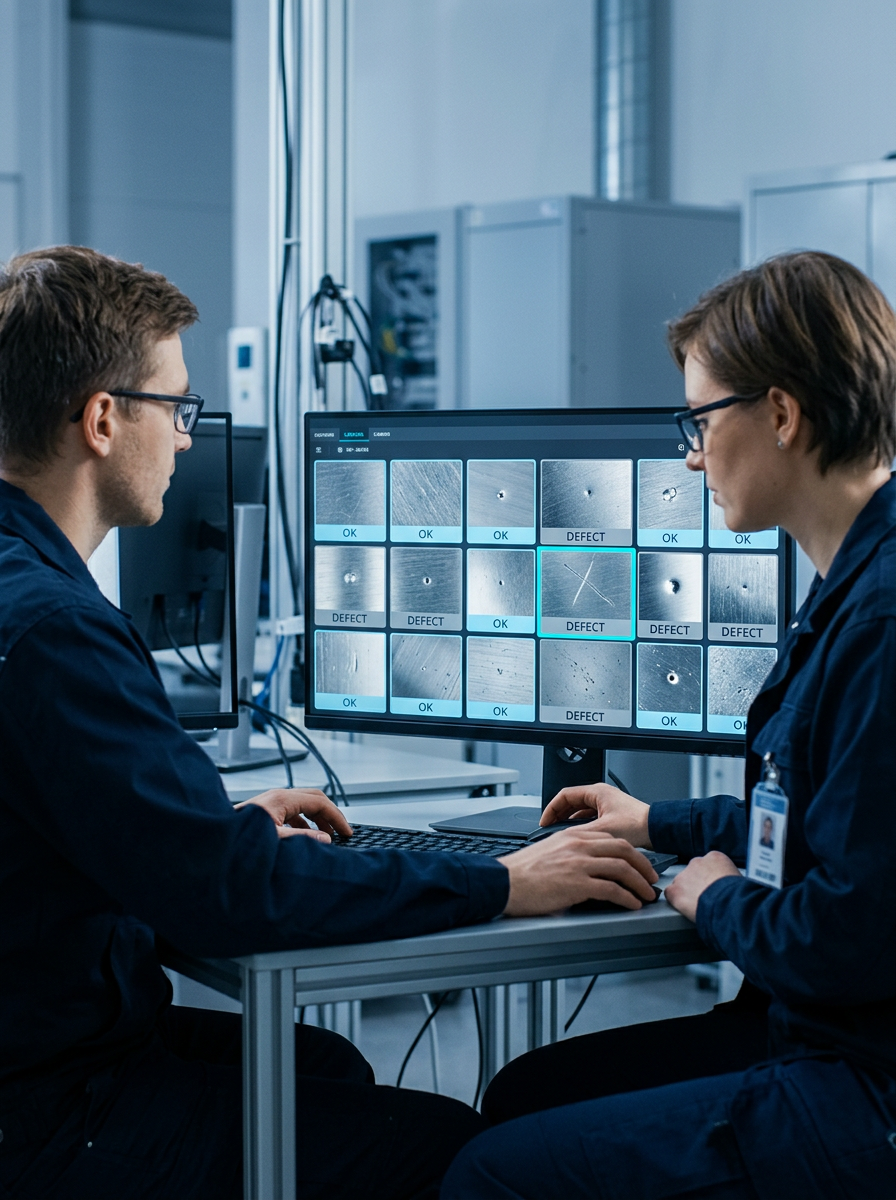
Candidate computer vision approaches are assessed specifically for reflections, lighting variability and micro-defects before a production-suitable method is selected.
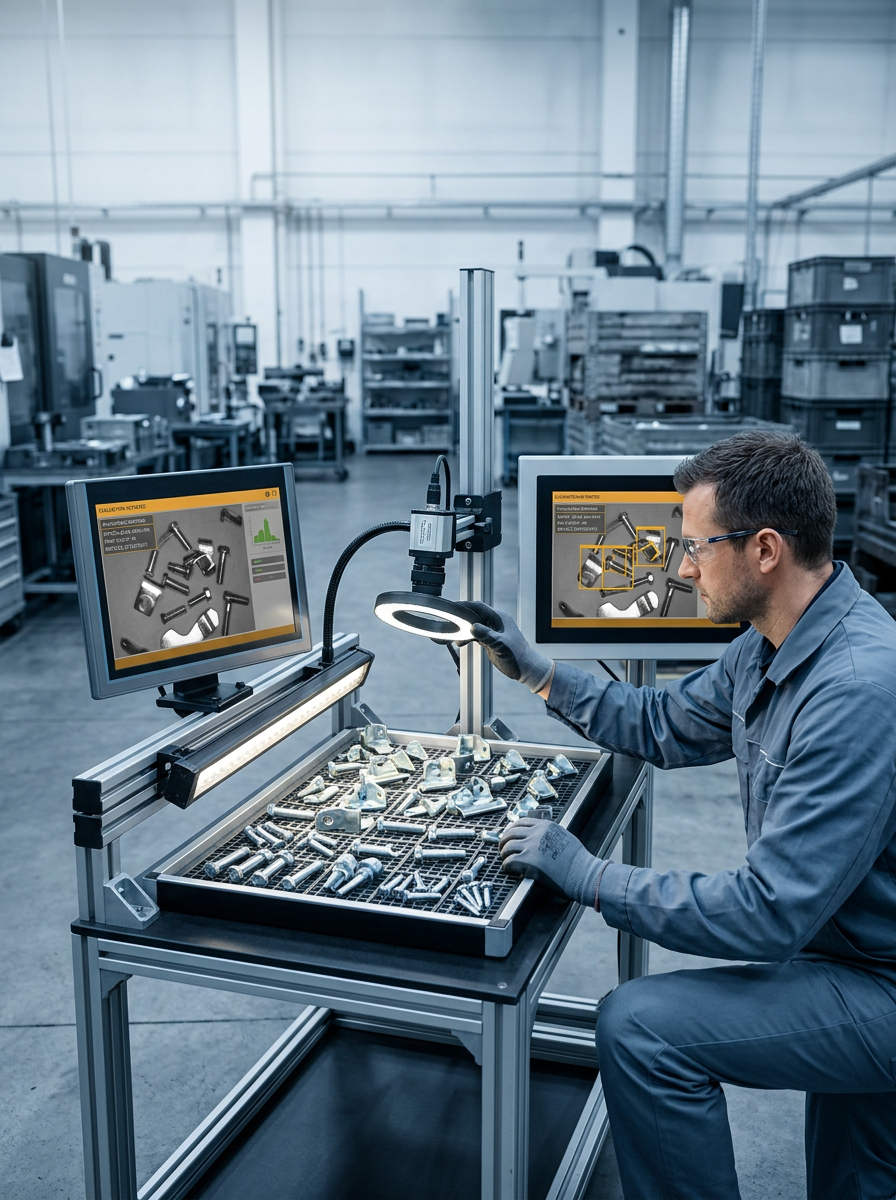
The final concept is prepared for low-latency edge inference and connection with existing handling or automation where those capabilities are already available.
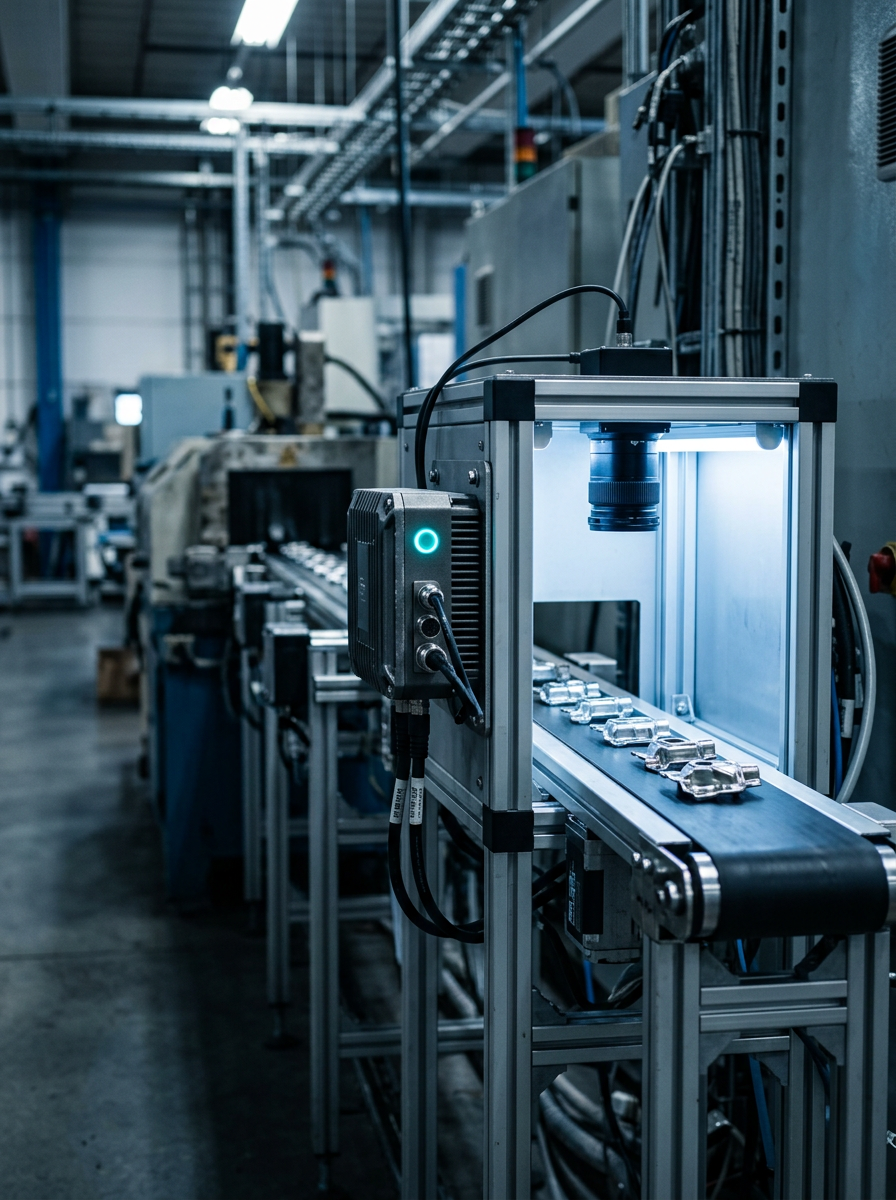
The documented evidence is qualitative, with performance governed by accuracy, false rejects, false accepts and robustness rather than reported percentage improvements.
Controlled image acquisition and computer vision establish a repeatable basis for acceptance decisions, reducing dependence on individual operator interpretation across production shifts.
Multi-camera acquisition is designed around complete surface coverage, giving the system access to defect evidence that a single viewpoint could miss.
The planned evolution moves beyond binary acceptance toward identification of the four to five defect categories considered most relevant to the process.
Edge-oriented inference and integration planning prepare the solution for real-time inspection within existing handling and automation environments.
Begin with measurable defect criteria, stable imaging and production-relevant validation, then extend the capability as classification maturity and operational robustness increase.
