- All Foundries

- Commodity Management & Trading

- Customer & Marketing Strategy

- Digital Engineering

- Station Studio

- Supply Chain & Industry 5.0

- Sustainability

- Physical AI

- Next-Gen Infrastructure

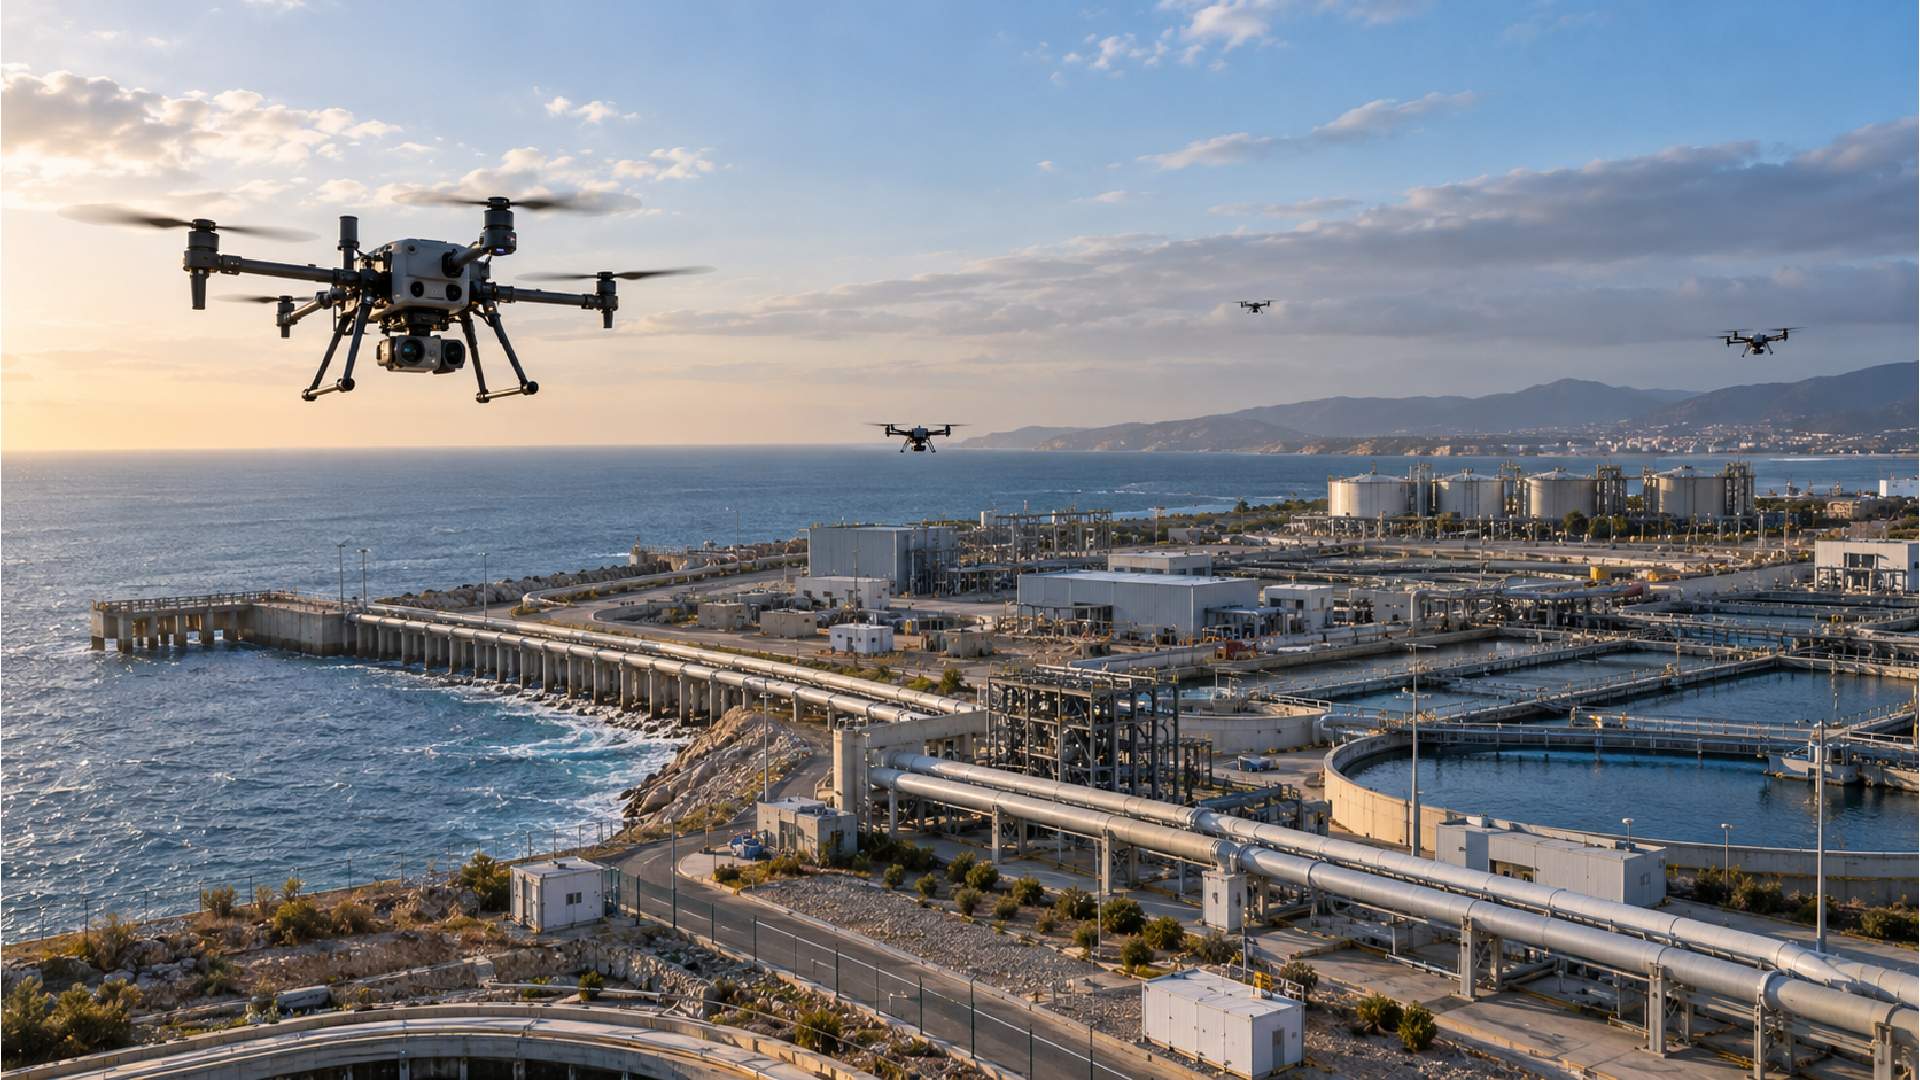
Multi-UAV system for autonomous inspection
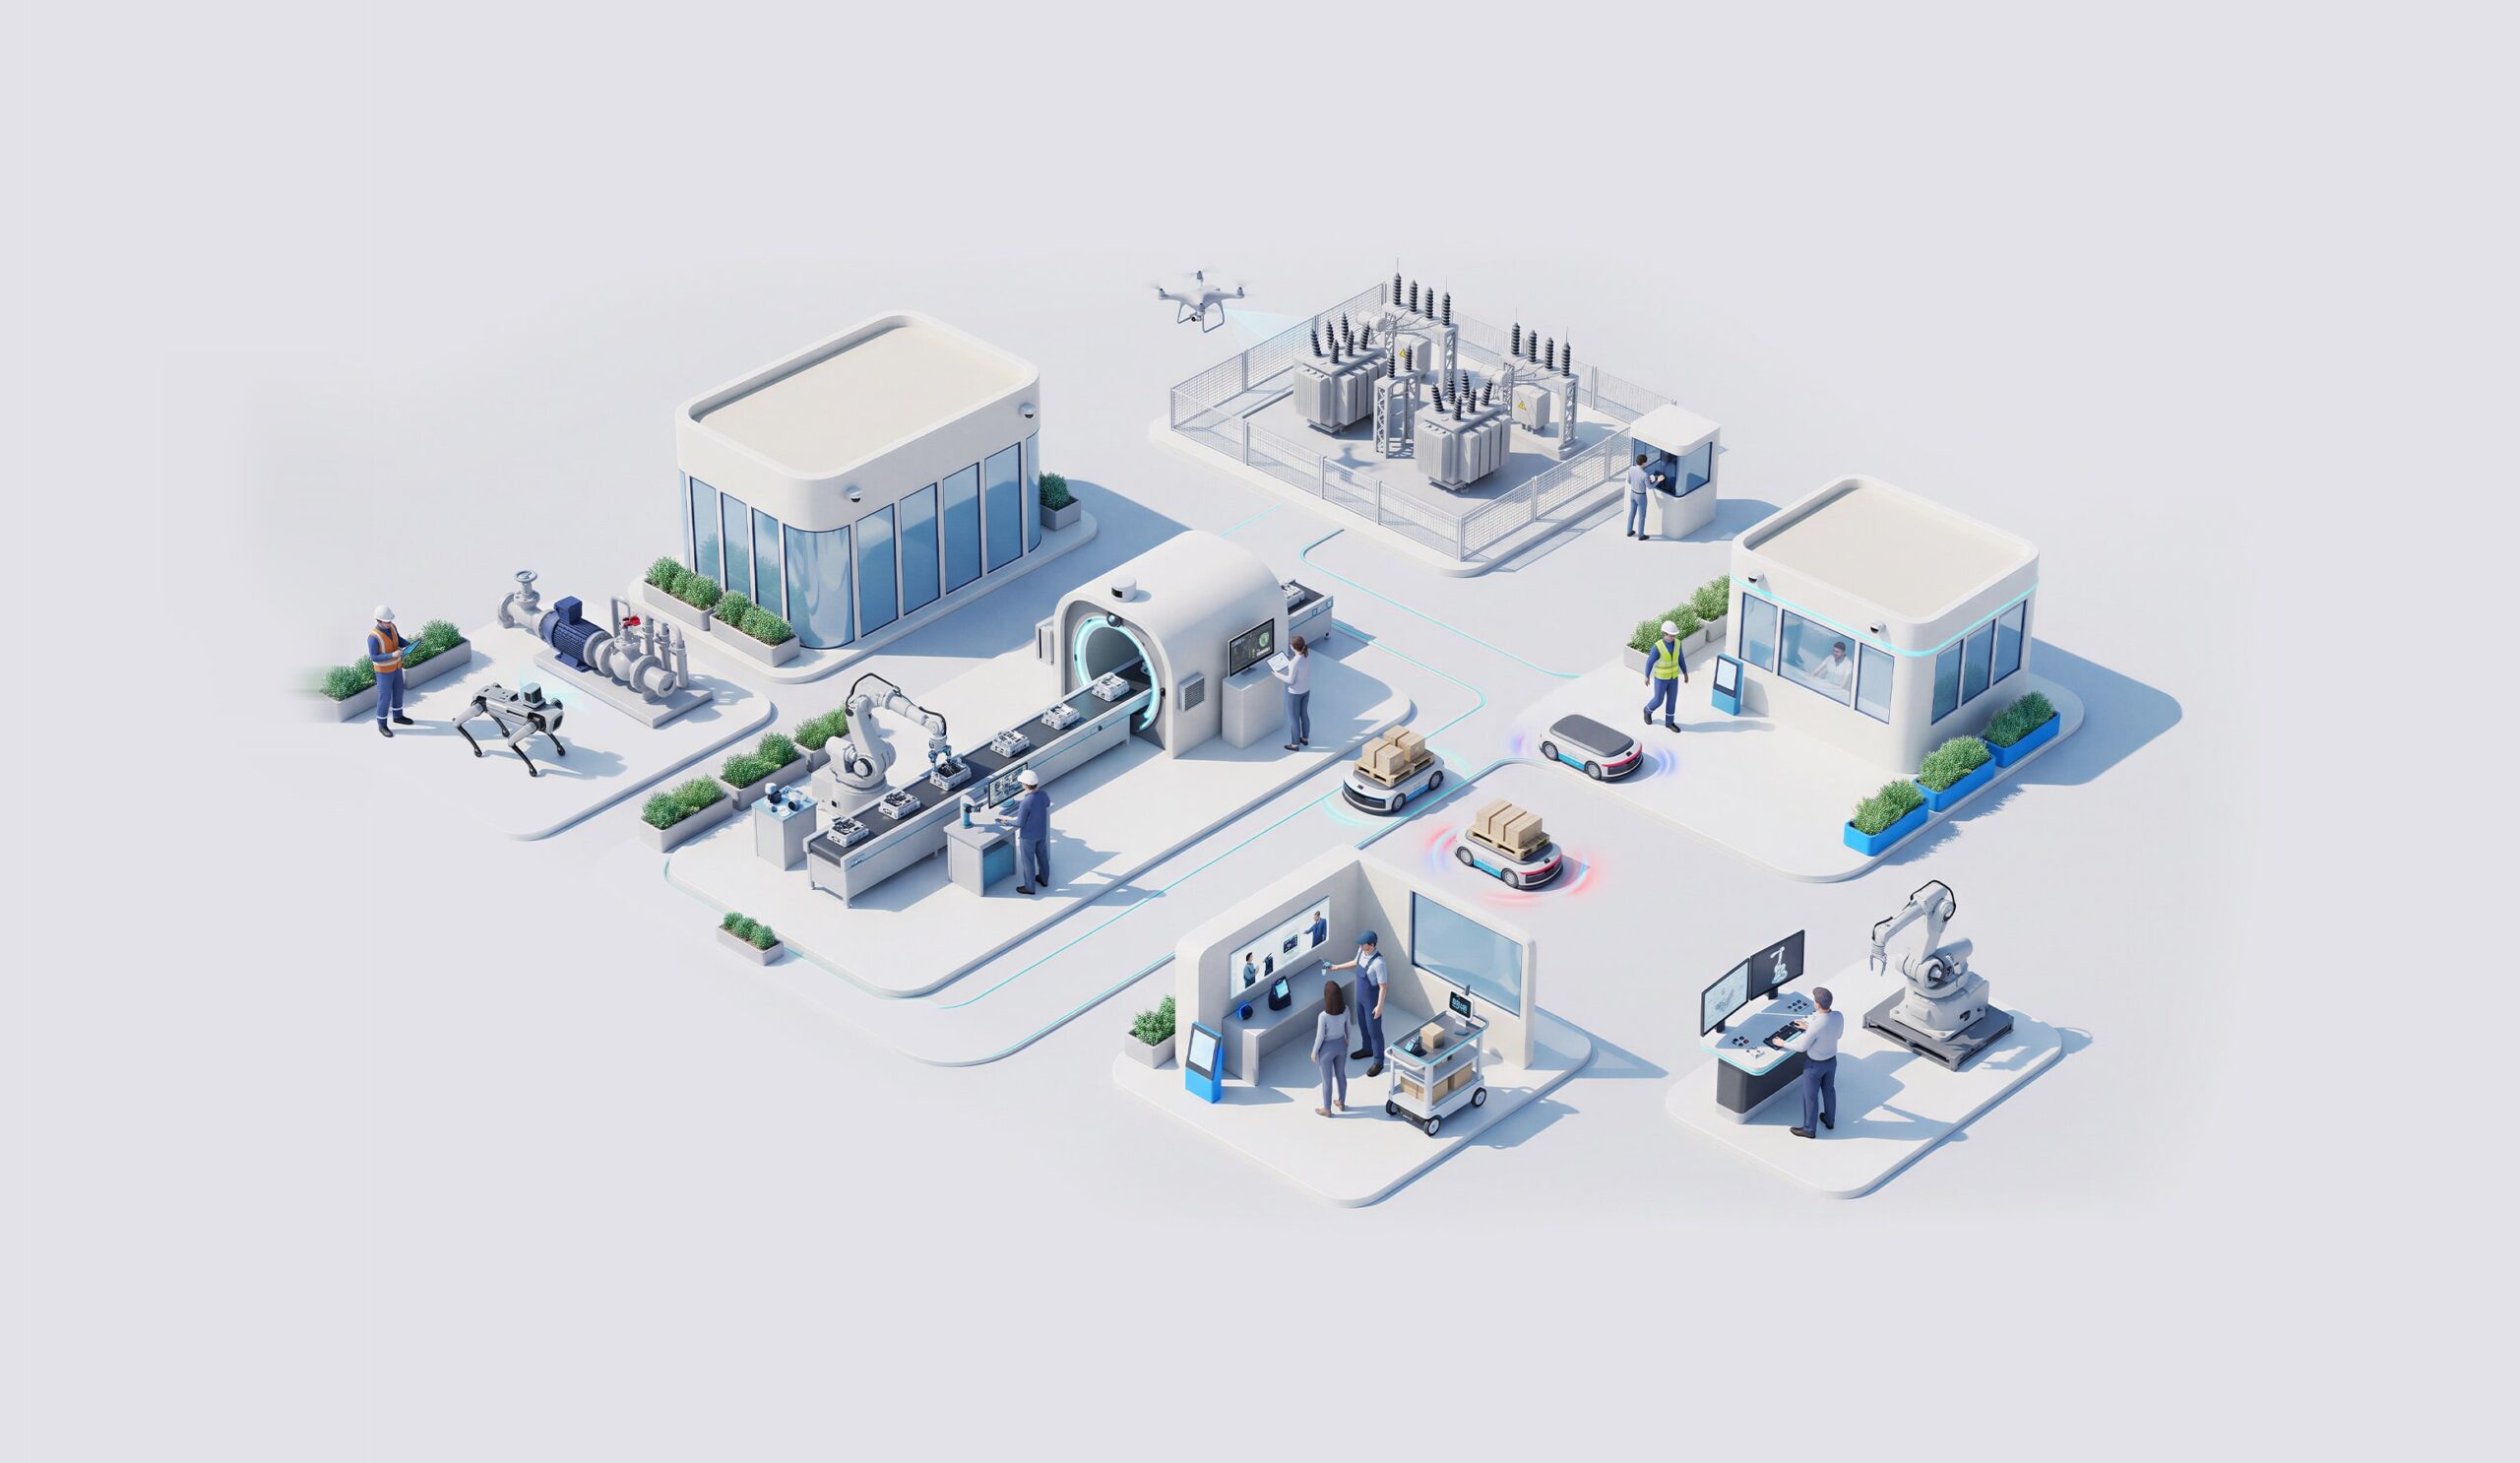
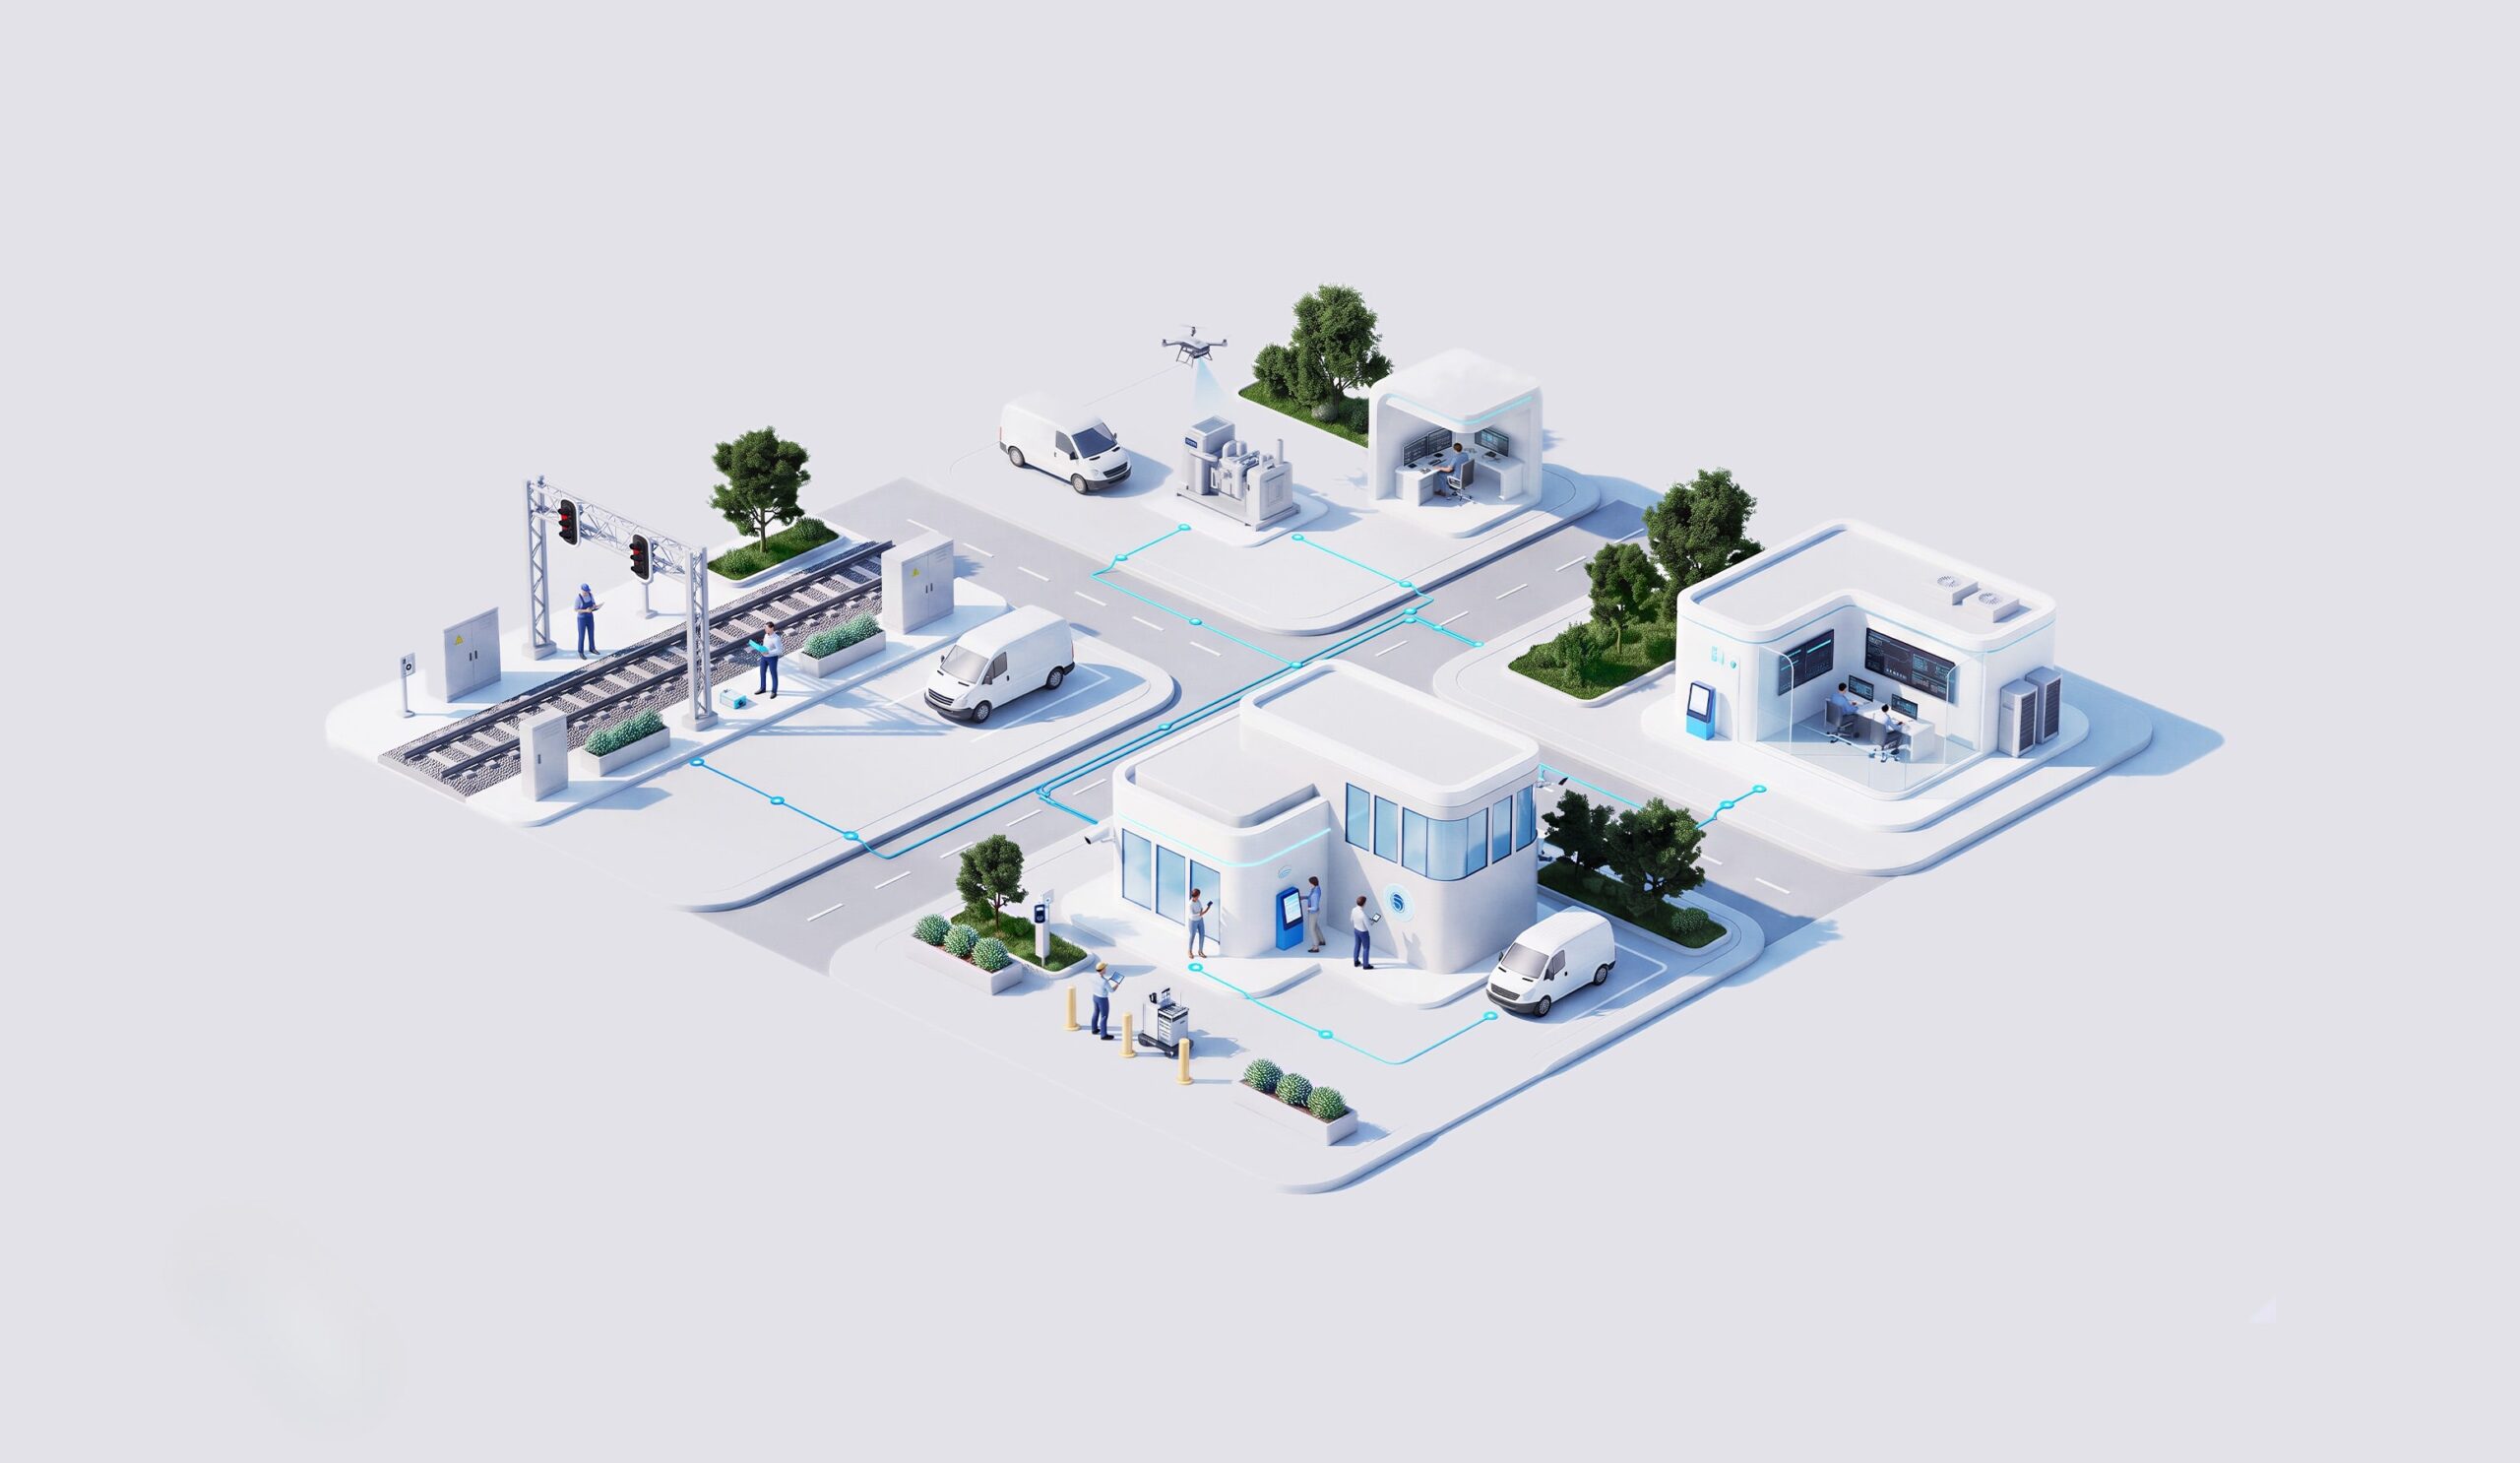
Critical infrastructure and private operational areas require responsive monitoring across broad and changing environments. Fixed surveillance cannot cover every location effectively, creating demand for mobile systems that can coordinate multiple UAVs, maintain reliable communications and adapt patrol behavior while delivering timely visual insight.
Cooperative UAVs improve monitoring reach and adaptability by combining coordinated flight optimization with real-time visual analysis.

Coordinated UAV fleets can optimize flight paths to cover inspection areas more effectively during autonomous surveillance missions.
Real-time visual analysis supports earlier detection and threat assessment across monitored infrastructure and private operational areas.
Weather-resilient computer vision supports visual analysis under rain, fog and changing lighting conditions that can affect conventional inspection quality.
Keep every drone in sync over robust links, ready for next-generation networks such as IOWN, designed for minimal latency.
How NTT DATA helps
NTT DATA develops autonomous fleet capabilities that manage multiple UAVs as a cooperative system for surveillance and infrastructure inspection.
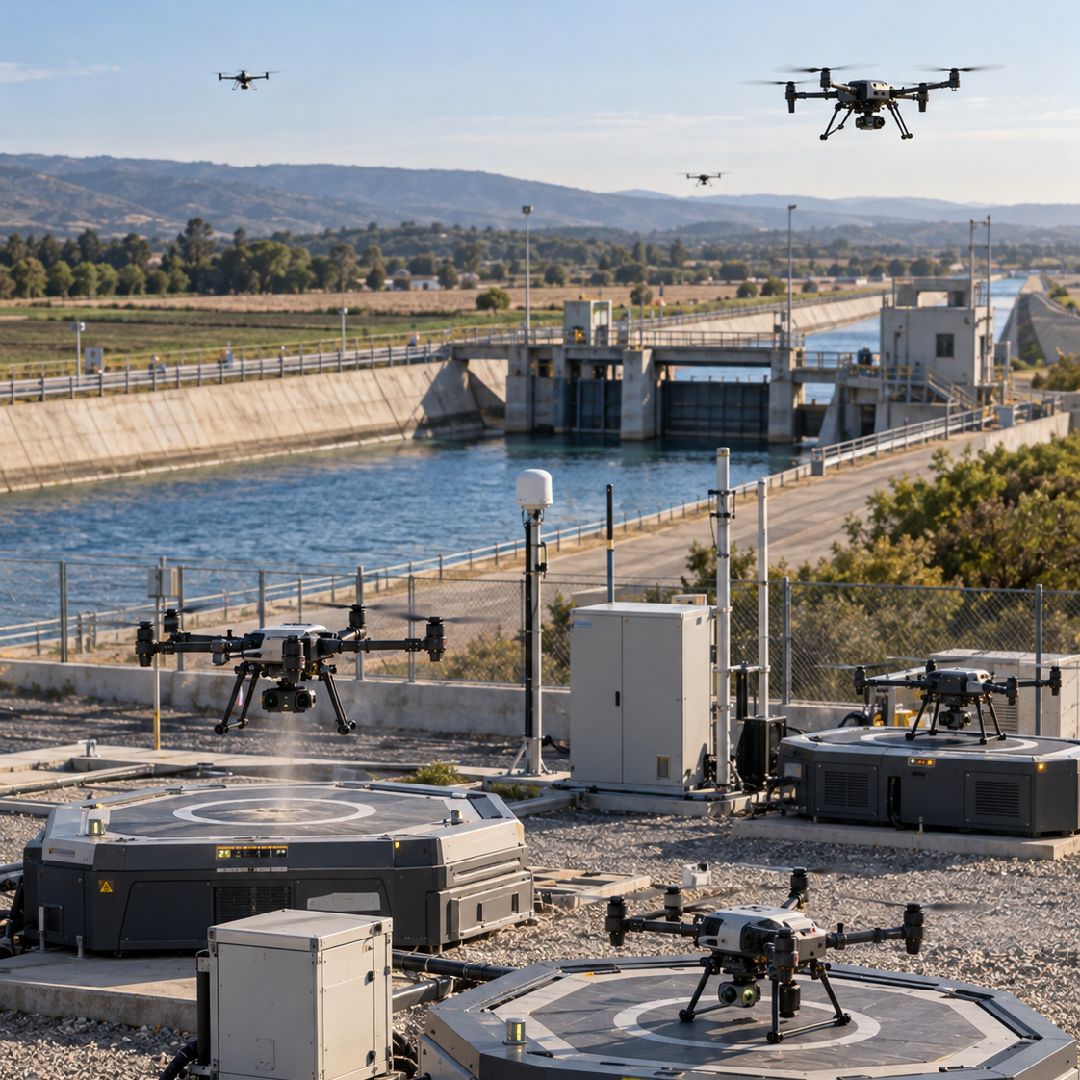
AI-driven control adjusts UAV routes to improve mission effectiveness and support complete area coverage.
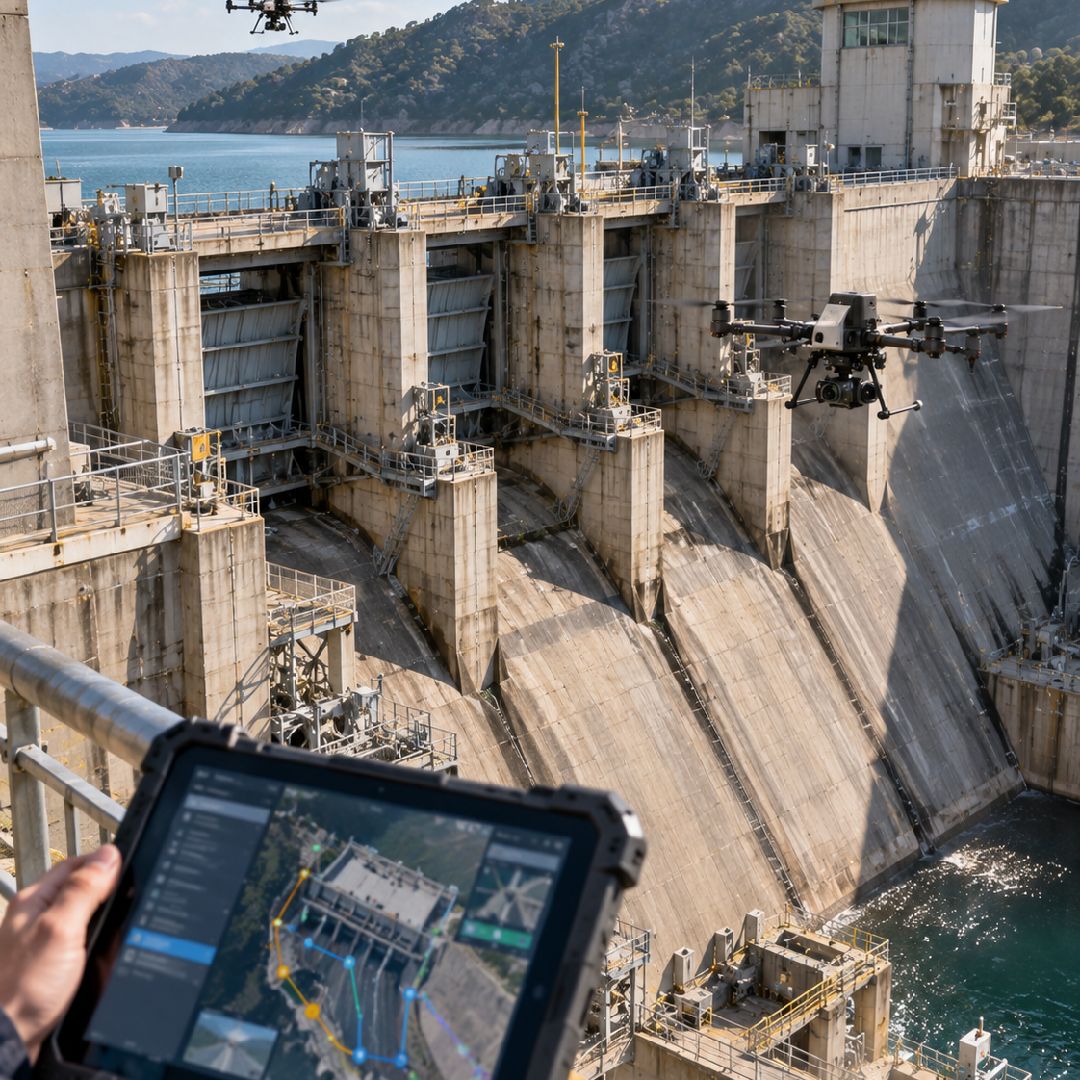
Patrol optimization considers coverage requirements, operational effectiveness and robust communication between drones during coordinated missions.
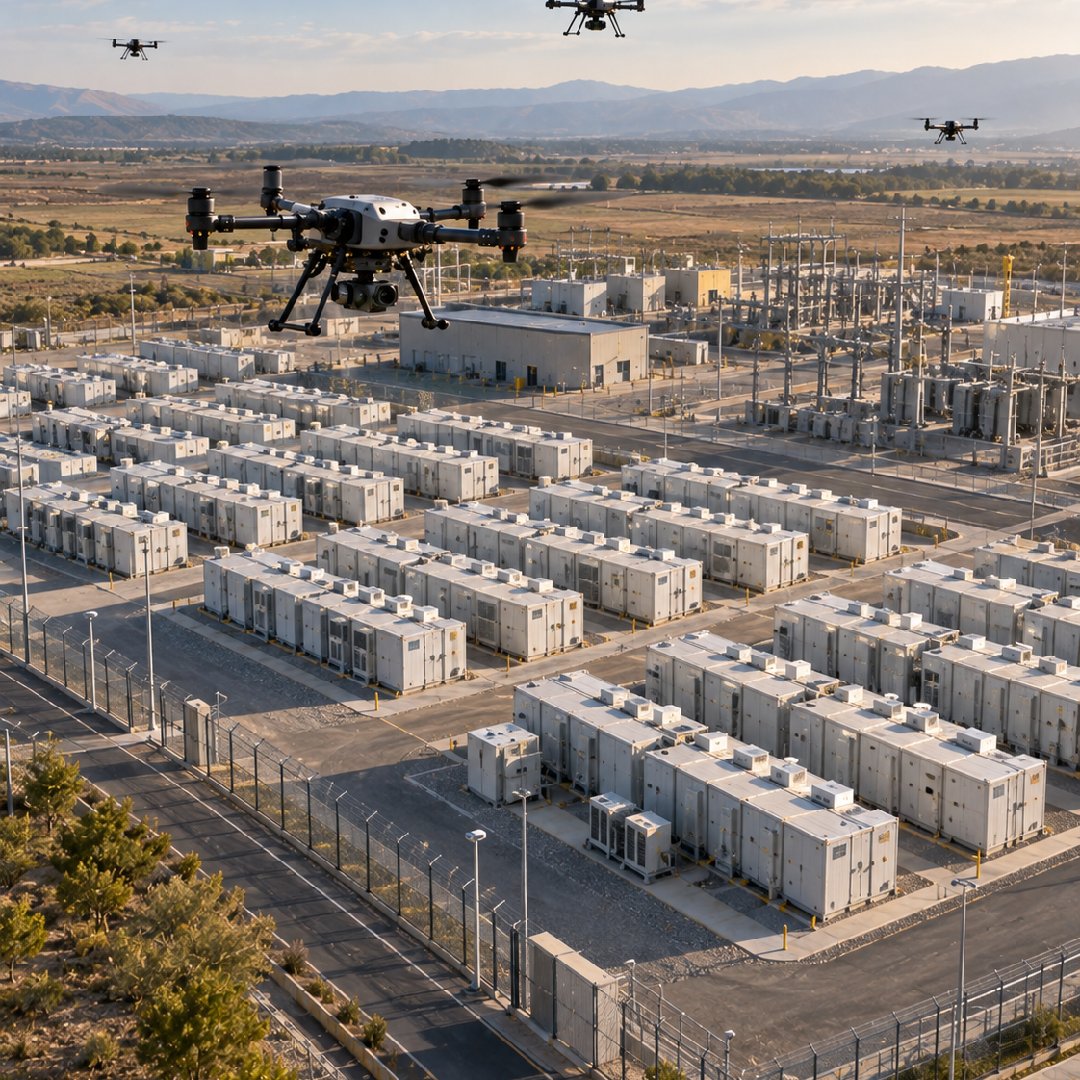
Visual analysis is designed to remain effective under variable weather and lighting conditions encountered during inspection activities.
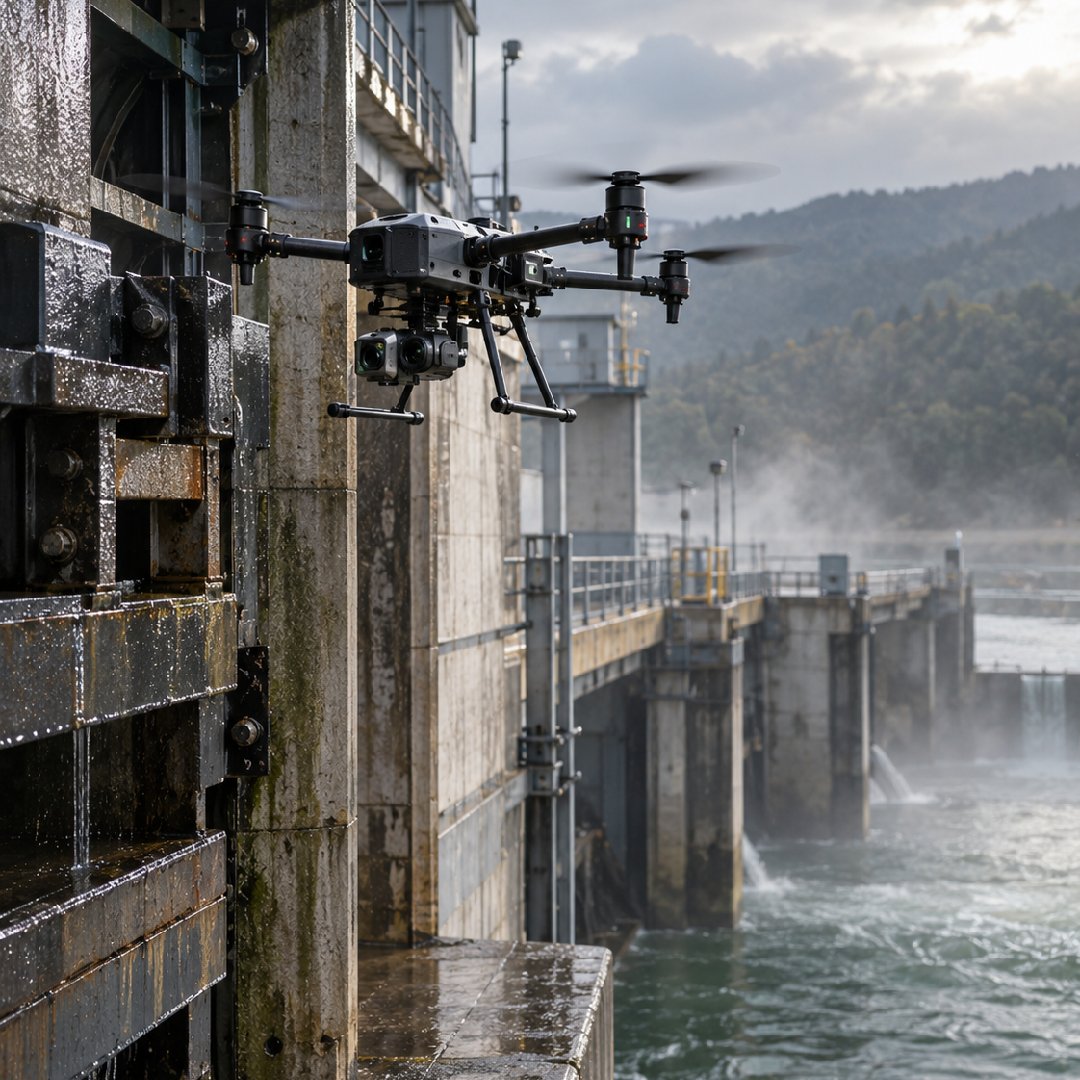
Give real-time insight into asset condition and threats, with inspection data kept under the infrastructure operator’s control.
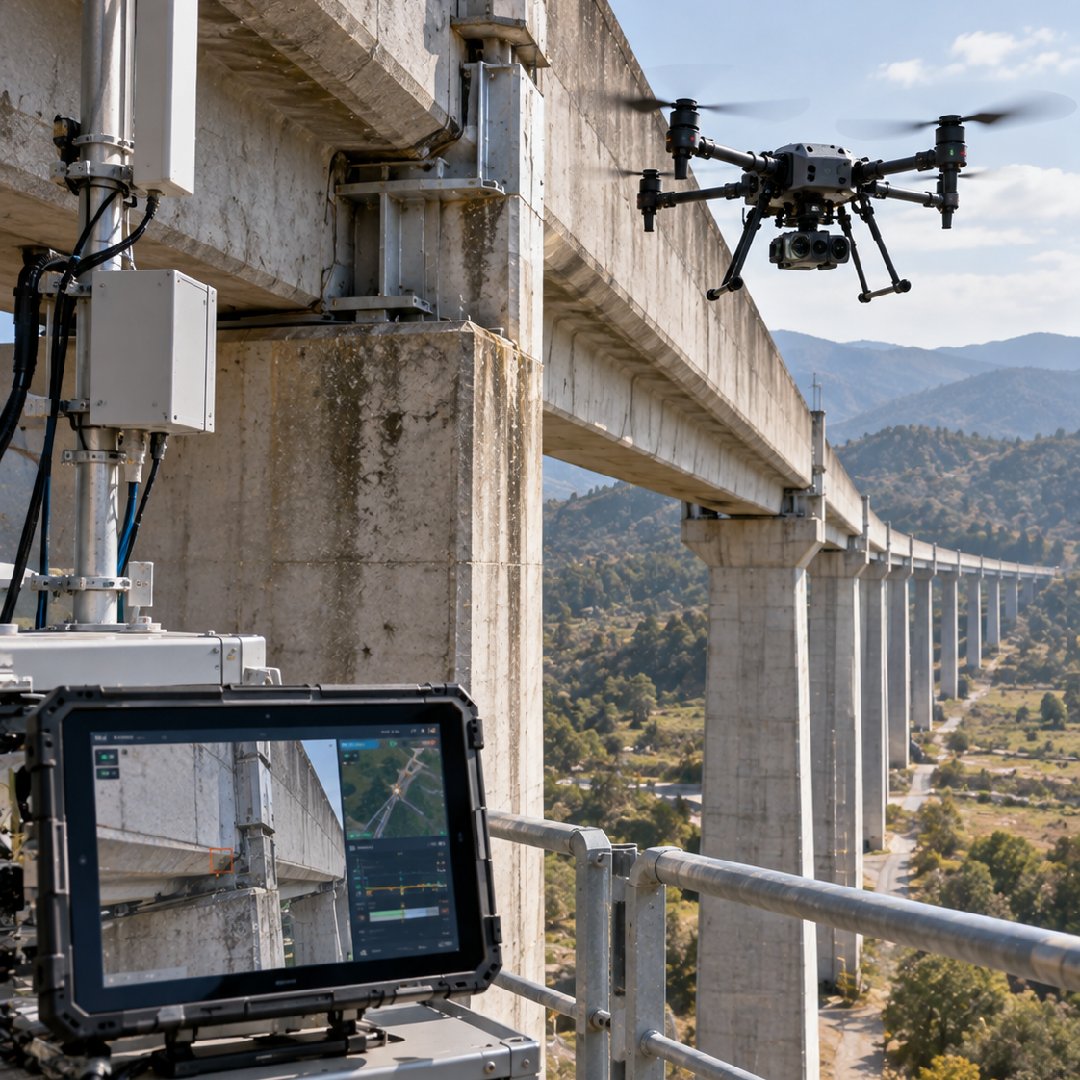
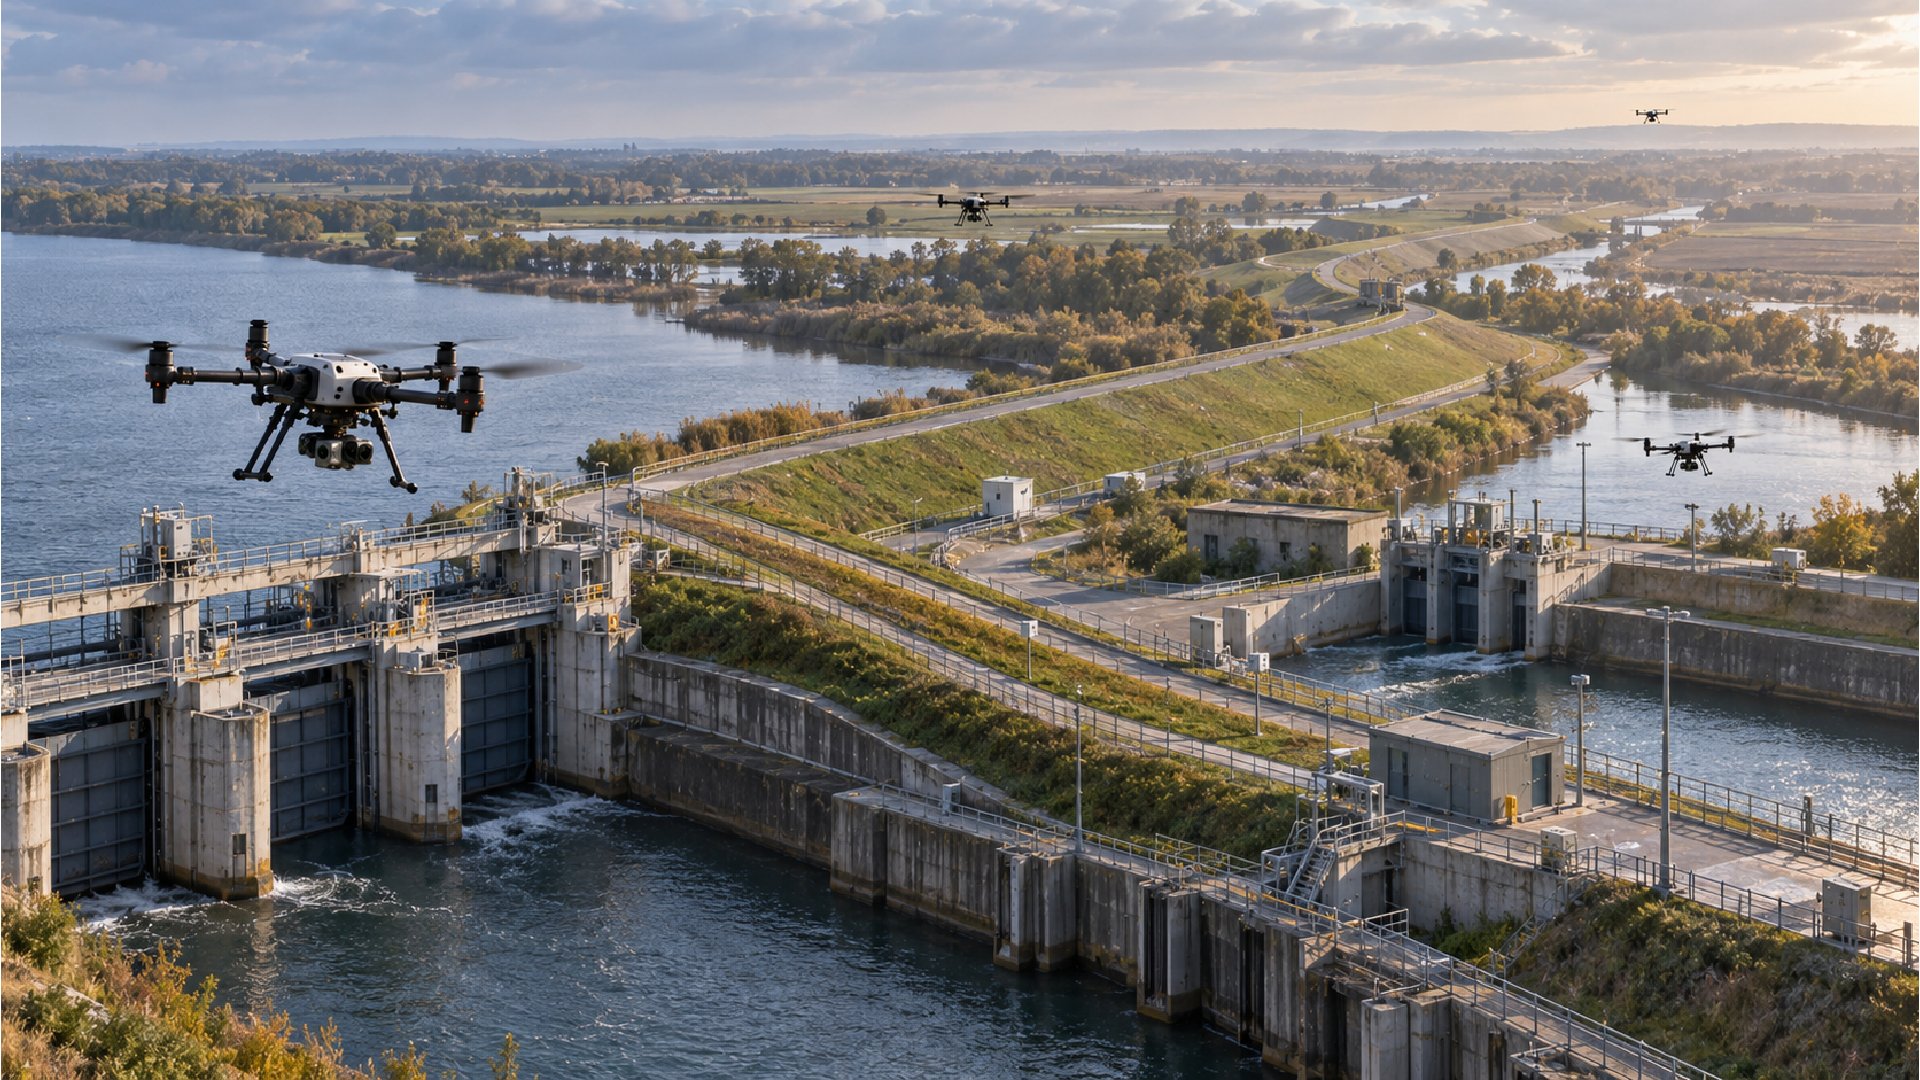
Real-time detection and threat assessment provide more immediate visibility into conditions across infrastructure and private areas during autonomous patrol operations.
Reinforcement learning optimizes UAV flight paths around mission objectives, supporting broader and more complete surveillance of designated operating areas.
Computer vision algorithms analyze visual information across rain, fog and changing light, supporting inspection continuity under challenging environmental conditions.
Communication-aware flight optimization helps multiple UAVs maintain robust links while operating together, supporting more consistent autonomous patrolling across complex environments.
Apply multi-UAV coordination, reinforcement learning and resilient computer vision to extend surveillance coverage and strengthen real-time critical infrastructure monitoring.